
Webinar on Finding the Monk Contest (How to Predict Where the Ocean Takes a Profiling Float)
01Finding The Monk: The Webinar Recap
Last week Dr. Paul Chamberlain of Scripps Institution of Oceanography co-hosted a Seatrec webinar with the winners of our first two Where’s the Monk? trajectory-prediction contests, walking through the actual science — and, by their own admission, the actual luck — behind forecasting where a drifting ocean float will surface, days out, with no fresh GPS fix to correct against. If you missed our winner write-ups, catch up here: José Manuel Echevarría Rubio, Round 1 and Knut-Frode Dagestad, Round 2.
02The Challenge, Recapped
The Monk is an infiniTE float — Seatrec’s patented ocean-thermal-energy-harvesting profiler, out testing in the Atlantic and the Gulf of Mexico. Since deployment, it has logged more than 300 days at sea, completed over 700 dive profiles, and covered more than 7,000 kilometers, diving roughly every 11 hours down to an average parking depth near 900–960 meters before resurfacing just long enough to transmit its position.
Seatrec co-founder Yi Chao had the idea to turn that into a community challenge: give participants the float’s last confirmed GPS fix and its full historical track, then ask them to predict where it would resurface roughly nine days later — no peeking in between. The team named the float “the Monk,” partly for its solitary life at depth, and partly as a nod to oceanographer Walter Munk.
Round 1 drew 24 entrants; only four landed within 100 km of the true surfacing position, and José Manuel Echevarría Rubio won with an error of just 52 km, with an honorable mention to Ruoying (Roy) He and the Fathom Science team at North Carolina State University, whose prediction also landed within 100 km — along with two other entrants. Round 2 was a tighter finish: three predictions landed within 100 km, and Knut-Frode Dagestad of MET Norway took it by just 61 km, with honorable mentions to Liesvy Valladares Alfonso (CICIMAR-IPN) and Zach Dubroc (Mississippi Coding Academies).
03Why Is This So Hard? The Physics of a Growing Error Bar

Paul opened by framing the question everyone was really asking: if you drop something in the ocean and track it for a week, why is 50+ km of error the good outcome? His answer came down to where the uncertainty comes from — and it changes character over time:
- Early on (the “ballistic” regime): uncertainty grows roughly in proportion to time — small early errors in current velocity compound quickly.
- Later (the “diffusive” regime): uncertainty grows more slowly, in proportion to the square root of time, as the trajectory effectively randomizes.
- Over the longest horizons: any systematic bias in the ocean model re-asserts itself, and error growth goes linear again.
Layered on top of that: ocean models like Copernicus GLORYS product and NOAA’s HYCOM typically resolve currents only down to a handful of kilometers — but real ocean motion includes sub-mesoscale eddies, internal waves, and wind-driven variability at scales models simply can’t see. And because profiling floats spend most of their life at depth rather than at the surface, predicting them means resolving the full three-dimensional current field, not just what satellites can observe from above.
“The choice of advection scheme, time step, and interpolation method all measurably shift a predicted trajectory — there’s no single ‘correct’ way to integrate a drifter forward, only trade-offs.”
— Dr. Paul Chamberlain
04Round 1: How José Manuel Won

José Manuel, a PhD candidate at CICIMAR-IPN studying sargassum transport in the Atlantic and Caribbean, adapted tools he already uses for tracking surface drifters to the Monk’s much deeper problem. Because the Monk spends more than 98% of its time below the surface, he built a three-phase dive model — roughly 30 minutes at the surface to transmit, a ~2.5 hour descent at 0.1 m/s, and around 7.5 hours parked near the deepest point of its dive (about 900 meters) — and sampled ocean currents at each phase separately, rather than assuming one depth for the whole trajectory. He discarded surface wind/wave (Stokes) drift entirely once testing confirmed it had no meaningful effect, since the float spends so little time at the surface.
Using Copernicus’s global Mercator current product (~9 km resolution, 8 depth levels) and OpenDrift for the simulation, he scored candidate configurations with the Liu–Weisberg skill score and ran a grid search (via scikit-learn) tuning a current “slip” coefficient and the length of the re-initialization window. His best setup — a 7-day reinitialization window and a current coefficient of 0.75 — produced a mean skill score of 0.96 across the float’s full 284-day history at the time (1.0 being a perfect match), and it’s what won him Round 1 with 52 km of error.
“You have to actually resolve the vertical dive cycle — not just the horizontal drift — to get this prediction right.”
— José Manuel Echevarría Rubio
His own lessons learned: the vertical dive cycle matters as much as horizontal current speed, shorter reinitialization windows keep errors from compounding, and trustworthy skill metrics matter more than chasing any one lucky-looking result.
05Round 2: How Knut-Frode Won — and What His Colleague’s Research Adds

Knut-Frode, lead developer of OpenDrift, found the contest post on LinkedIn just two days before the Round 2 deadline and built his entry solo, in what he candidly called an “embarrassingly simplistic” version of José Manuel’s approach. He pulled the float’s historical track into Trajan (a standalone Python trajectory-analysis package originally built inside OpenDrift, now spun out so it can score any drift model’s output against observed tracks), then tested his simulation against the real historical positions. His first pass — surface currents only — performed poorly, as expected, since the Monk spends almost no time at the surface. His second pass, holding the float at a single eyeballed depth of 700 meters (versus José Manuel’s calculated ~900–960 meters), tracked the real trajectory far more closely, and that’s the current field he ultimately trusted for his forecast.
Rather than over-engineer it further, he made a judgment call: since forecast errors compound regardless of method, and Round 2 had fewer entrants than Round 1, the odds favored a good-enough model over a heavily-tuned one. He was open that part of this was a bet on variance:
“It’s a little bit like playing poker — in a single game, anyone can win, but in the end the winner is the one with the best strategy. We hope to do something more robust next time.”
— Knut-Frode Dagestad
His MET Norway colleague Jean Rabault joined to share related bias-correction research from an earlier DARPA ocean-prediction competition: combining multiple current products — satellite-derived (like Globcurrent) and model-based (Mercator, HYCOM, OSCAR) — with a simple linear regression outperformed any single product by 30–40% on the Liu–Weisberg skill score. A neural network trained on the same inputs didn’t beat the linear model, suggesting the individual products’ errors are already close to a fixed offset rather than a complex nonlinear relationship. On ensemble modeling more broadly: the best-performing ensemble member tends to stay best for only the next 1–2 days, but a bad member tends to stay bad for 7–10 days — making it more valuable to filter out consistently poor members than to chase the single best one.
06From the Q&A, and What’s Next
Is the deep ocean less chaotic than the surface?
Javier Zavala-Garay asked how dispersive currents are at 500–1,000 meters compared to the wind-driven surface layer. José Manuel’s view: deeper water masses are more thermally homogeneous and likely less stochastic than the surface mixed layer. Paul pointed to the DIMES experiment — which acoustically tracked floats in the Antarctic Circumpolar Current — as real-world evidence that meaningful current variability exists at depth too, even if it behaves differently than surface turbulence.
Could Lagrangian Coherent Structures help?
Sebastién Legrand raised the idea of using LCS/attractor analysis to flag when a trajectory is entering a region likely to bend a prediction off course. Knut-Frode had experimented with this before and wasn’t convinced it adds much beyond what a good drift simulation already captures — but was open to being wrong about it.
What’s the single easiest next improvement?
Both winners agreed: more complete dive-cycle metadata from Seatrec — exact time-at-surface and time-at-depth per dive — would sharpen everyone’s models. Yi Chao acknowledged that data exists but isn’t well surfaced today, and committed to publishing it more clearly for future rounds.
Looking ahead, Seatrec plans to run the Monk contest on a monthly cadence (weekly proved to be too much of a good thing), likely featuring a different float and location next round. Prizes escalate with repeat wins too — from a t-shirt, up to a jacket, up to a Seatrec cooler bag for anyone who takes the top spot three times. A well-earned congratulations to both winners — and a special shoutout to José Manuel, who successfully defended his PhD dissertation just two days after this session.
Join the Next Contest
Predicting Float Trajectories
Follow Seatrec for the announcement of the next contest and webinar.


We have a Winner! Where's the Monk Contest: Part 2

01We have another Winner!

Meet Knut-Frode Dagestad, our second Where’s the Monk winner — a senior researcher at MET Norway (Norwegian Meteorological Institute | Meteorologisk institutt) who landed the closest guess of all: just 61 km from where The Monk actually surfaced on July 20, 2026.
But he didn’t just predict The Monk’s position — he helped build the tool that made it possible. Knut-Frode is a co-developer of OpenDrift, the trajectory-modeling framework our first winner, José Manuel Echevarría Rubio, used to win the contest. The two have never met, or even spoken — Knut-Frode only learned of the connection when José Manuel’s LinkedIn post about the win crossed his feed.
02The Results
This round came down to a tight finish: three predictions landed within 100 km of The Monk’s actual surfacing position. Knut-Frode’s guess placed him closest of all — just 61 km out. Honorable mention goes to Liesvy Valladares Alfonso, a Physical Oceanographer and PhD Candidate at CICIMAR-IPN (Centro Interdisciplinario de Ciencias Marinas, Instituto Politécnico Nacional) in La Paz, Baja California Sur, Mexico, whose prediction also landed within 100 km — the very same institution as our first contest’s winner, José Manuel Echevarría Rubio. The other honorable mention goes to Zach Dubroc, Instructor at the Mississippi Coding Academies.
03The Winning Prediction
“I only discovered this competition after it was two or three days before the deadline, so I did it — I would say, embarrassingly simple approach. If I had more time, I’d do something more along the lines of what José Manuel did, because he did a much more sophisticated job. But I was in a hurry, so I did it almost primitively.”
— Knut-Frode Dagestad
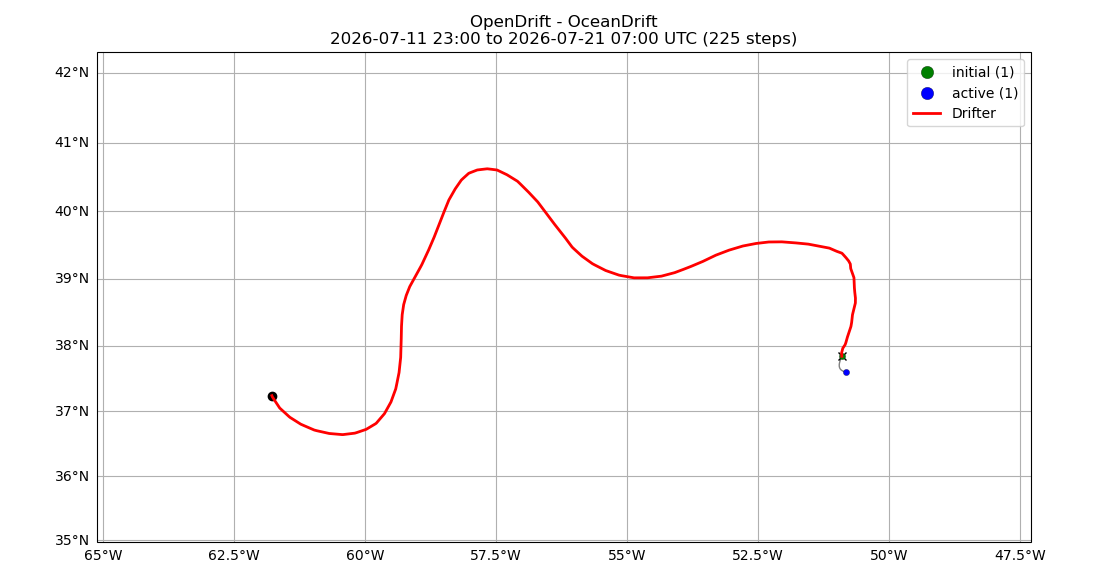
Here’s the forecast he ultimately submitted — run forward from The Monk’s last known position using currents at 700 meters depth, pulled from the Copernicus Marine Service’s Global Ocean Analysis and Forecast product — the Mercator global model.
To trust that current field, he tested it against history first. Using the float’s known track from June 1 to July 12, he simulated 24 hours of drift starting from each day’s position, then checked whether the simulated endpoint lined up with where the float actually was the next day.

For comparison, he ran the same test using surface currents instead — checked against the actual track, the surface-current simulations drift visibly off course.

Looked at on their own, without the historical track for reference, those surface-current simulations don’t reveal anything wrong.

But checked the same way against the real track, the 700-meter-depth simulations hug the historical path far more closely — confirming which current field to trust.

“There’s a lot of randomness, a lot of uncertainty in this. It’s like — a dice roll will take it.”
— Knut-Frode Dagestad
This time, the dice landed within 61 km.
04The Interview
What drew you into oceanography in the first place?
“I wanted to study theoretical quantum physics, or something more hardcore physics. But then I found it interesting, though a little far from everyday life — and very narrow. I think it’s nice to do something more related to everyday life, something normal people can relate to.”
“So then meteorology — that was quite interesting. It was actually more mathematical and physical than I expected, because people on the street would say it’s guesswork. They don’t know how much physics is behind meteorology. I liked that it was relevant to society, and still interesting.”
He grew up about an hour inland from Bergen, Norway — near a lake, not the ocean. But I think most people feel attached to the ocean regardless. For me, though, it wasn’t really the ocean itself — it was more the physics, the problem-solving, and a bit of randomness that led me first into meteorology, and then into oceanography, because the two are so connected — you can’t really study one without the other.”
How did OpenDrift come about?
“We already had a service, with some older models running — but we had three different models in three different programming languages. What we realized is there’s so much overlap between oil-spill modeling, search-and-rescue drift modeling, dust modeling, and iceberg modeling that we just made one framework, with separate models for each specific task built on top of it. So we made one generator instead of three separate ones.”
Knut-Frode has worked at MET Norway for about ten or eleven years, building tools for exactly this kind of problem: modeling where things — oil, people and objects in search-and-rescue cases, dust, icebergs — end up carried by ocean currents.
Did you use machine learning for this prediction?
“We do drift modeling with machine-learning corrections at times, but in this case I didn’t use it, because my colleague who works on the machine-learning side was on vacation, and I didn’t want to disturb him. Next time, we’ll add a machine-learning correction to it.”
“I don’t believe in an approach where you use only machine learning. You need a physical grounding as your basis, and you use machine learning as a correction — a post-processing step for the part you can’t otherwise model, the part you can’t fully understand but can fit with machine learning.”
Any advice for people entering the next contest, or using OpenDrift generally?
“I don’t think I’d give advice, because I think it’s good that there’s variability — that people test different approaches. If everyone agreed on the same advice, we’d all end up more uniform, and it might turn out that an approach we didn’t believe in works better. So I wouldn’t give advice — but for my own sake, I believe in a combination of physics as a foundation and a bit of machine learning. Not too much, but a good combination. It’s a fantastic tool — you just have to figure out where to use it and where not to. I think that’s true not just in oceanography, but in society as a whole.”
On the value of the contest format itself:
“I think this competition is not only fun — it’s really useful for everyone involved. It’s a deadline, and you don’t know the answer, so you really need to think and sharpen yourself before submitting. If you’re a researcher just playing with data you already have, you can be focused, but it’s not the same sharpness.”
05What’s Next
There’s more to come — Knut-Frode will be joining us live for “Finding The Monk: How to Predict Where the Ocean Takes a Float,” a walkthrough of the trajectory-prediction techniques behind this win, including the surface-vs-depth validation test and the forecast run above. Bring your questions — he’ll be there to answer them live.
Save the Date
Finding The Monk: How to Predict Where the Ocean Takes a Float
Tuesday, August 18, 2026 · 9:00 AM PDT

Where's the Monk Contest Challenge Continues : Part 2

01The Challenge Continues!
Our first Where’s the Monk contest wrapped up with a winner — read how José Manuel Echevarría Rubio, PhD Candidate in Marine Sciences at CICIMAR-IPN nailed his prediction — and now we’re back with a new stretch of ocean, a new contest, and a new deadline: July 20, 2026 at 11:59 PM PDT. Position updates revealed until July 13, 2026 at 11:59 PM PDT.
Somewhere along the North Atlantic, a profiling float named “The Monk” is drifting along — guided by currents, thermoclines, and the physics of the ocean. It’s one of Seatrec’s infiniTE™ floats, powered by thermal energy harvested from the temperature gradient between warm surface waters and the cold deep.
We know its last confirmed position. What we don’t know — and what we’re asking you to figure out — is exactly where The Monk will surface on July 20, 2026 at 11:59 PM PDT.
No hints. Just your read of the ocean, or your most inspired guess. Use the live tracker to study its trajectory. Dig into Gulf Stream data. Or go with your gut. Closest guess wins — ties broken by earliest submission.
Contest Brief
|
⏰ Contest Deadline July 20, 2026 · 11:59 PM PDT
|
🔍 Track Live 📅 Position Updates REVEALED Until July 13, 2026 · 11:59 PM PDT |
02What Is the infiniTE™ Float?
The infiniTE™ is Seatrec’s flagship ocean profiling float, designed to operate autonomously for years without battery replacement — harvesting energy from the ocean’s natural temperature gradient to power itself and collect critical oceanographic data on every dive cycle.
The Monk has been tracing the currents of the Atlantic, and its track tells a story of eddies, meanders, and the Gulf Stream system. Where it ends up next is yours to predict.
🏆
Win the Exclusive Seatrec T-Shirt

The winner receives this exclusive Seatrec “Infinite Energy · Deeper Insights” infiniTE™ T-shirt — limited edition, not for sale.
One Winner · Closest Coordinates Wins
03How to Enter
To win the shirt, study the tracker, make your prediction, and submit your coordinates. Closest entry wins. Ties broken by the earliest valid submission. We’ll announce the winner shortly after July 20th.
|
STEP 01 Study the trackerWatch The Monk’s trajectory at the live tracking link. Positions update through July 13, 2026 · 11:59 PM PDT. |
STEP 02 Make your predictionPick a latitude and longitude for where The Monk will surface on July 20, 2026 at 11:59 PM PDT. |
|
STEP 03 Submit coordinatesDrop your numbers into the official entry form before the deadline. |
STEP 04 Win the shirtClosest entry wins. Ties broken by the earliest valid submission. We’ll announce the winner shortly after July 20. |
The Series Continues
The Monk is Continuing its Journey
Our next contest is live. Same float, new currents, new prediction, new chance to win.

We have a Winner! Where's the Monk Contest: Part 1

01We have a Winner!

Our first Where’s the Monk contest asked one question: where would The Monk — one of Seatrec’s infiniTE™ floats, drifting along the North Atlantic — surface on July 5, 2026, at the closest time before 11:59 PM PDT? Predictions came in from around the world. Landing within 100 km of a float that’s been riding the Gulf Stream’s eddies and meanders for two weeks is genuinely hard — only four entries managed it. And when the Monk surfaced at 38.5626°N, 50.6690°W, at 3:27 PM PDT, one prediction stood closest of all, just 52 km away: José Manuel Echevarría Rubio, PhD Candidate in Marine Sciences at CICIMAR-IPN. (Shout out to his advisor, Dr. Guillermo Martínez-Flores!).
02The Results
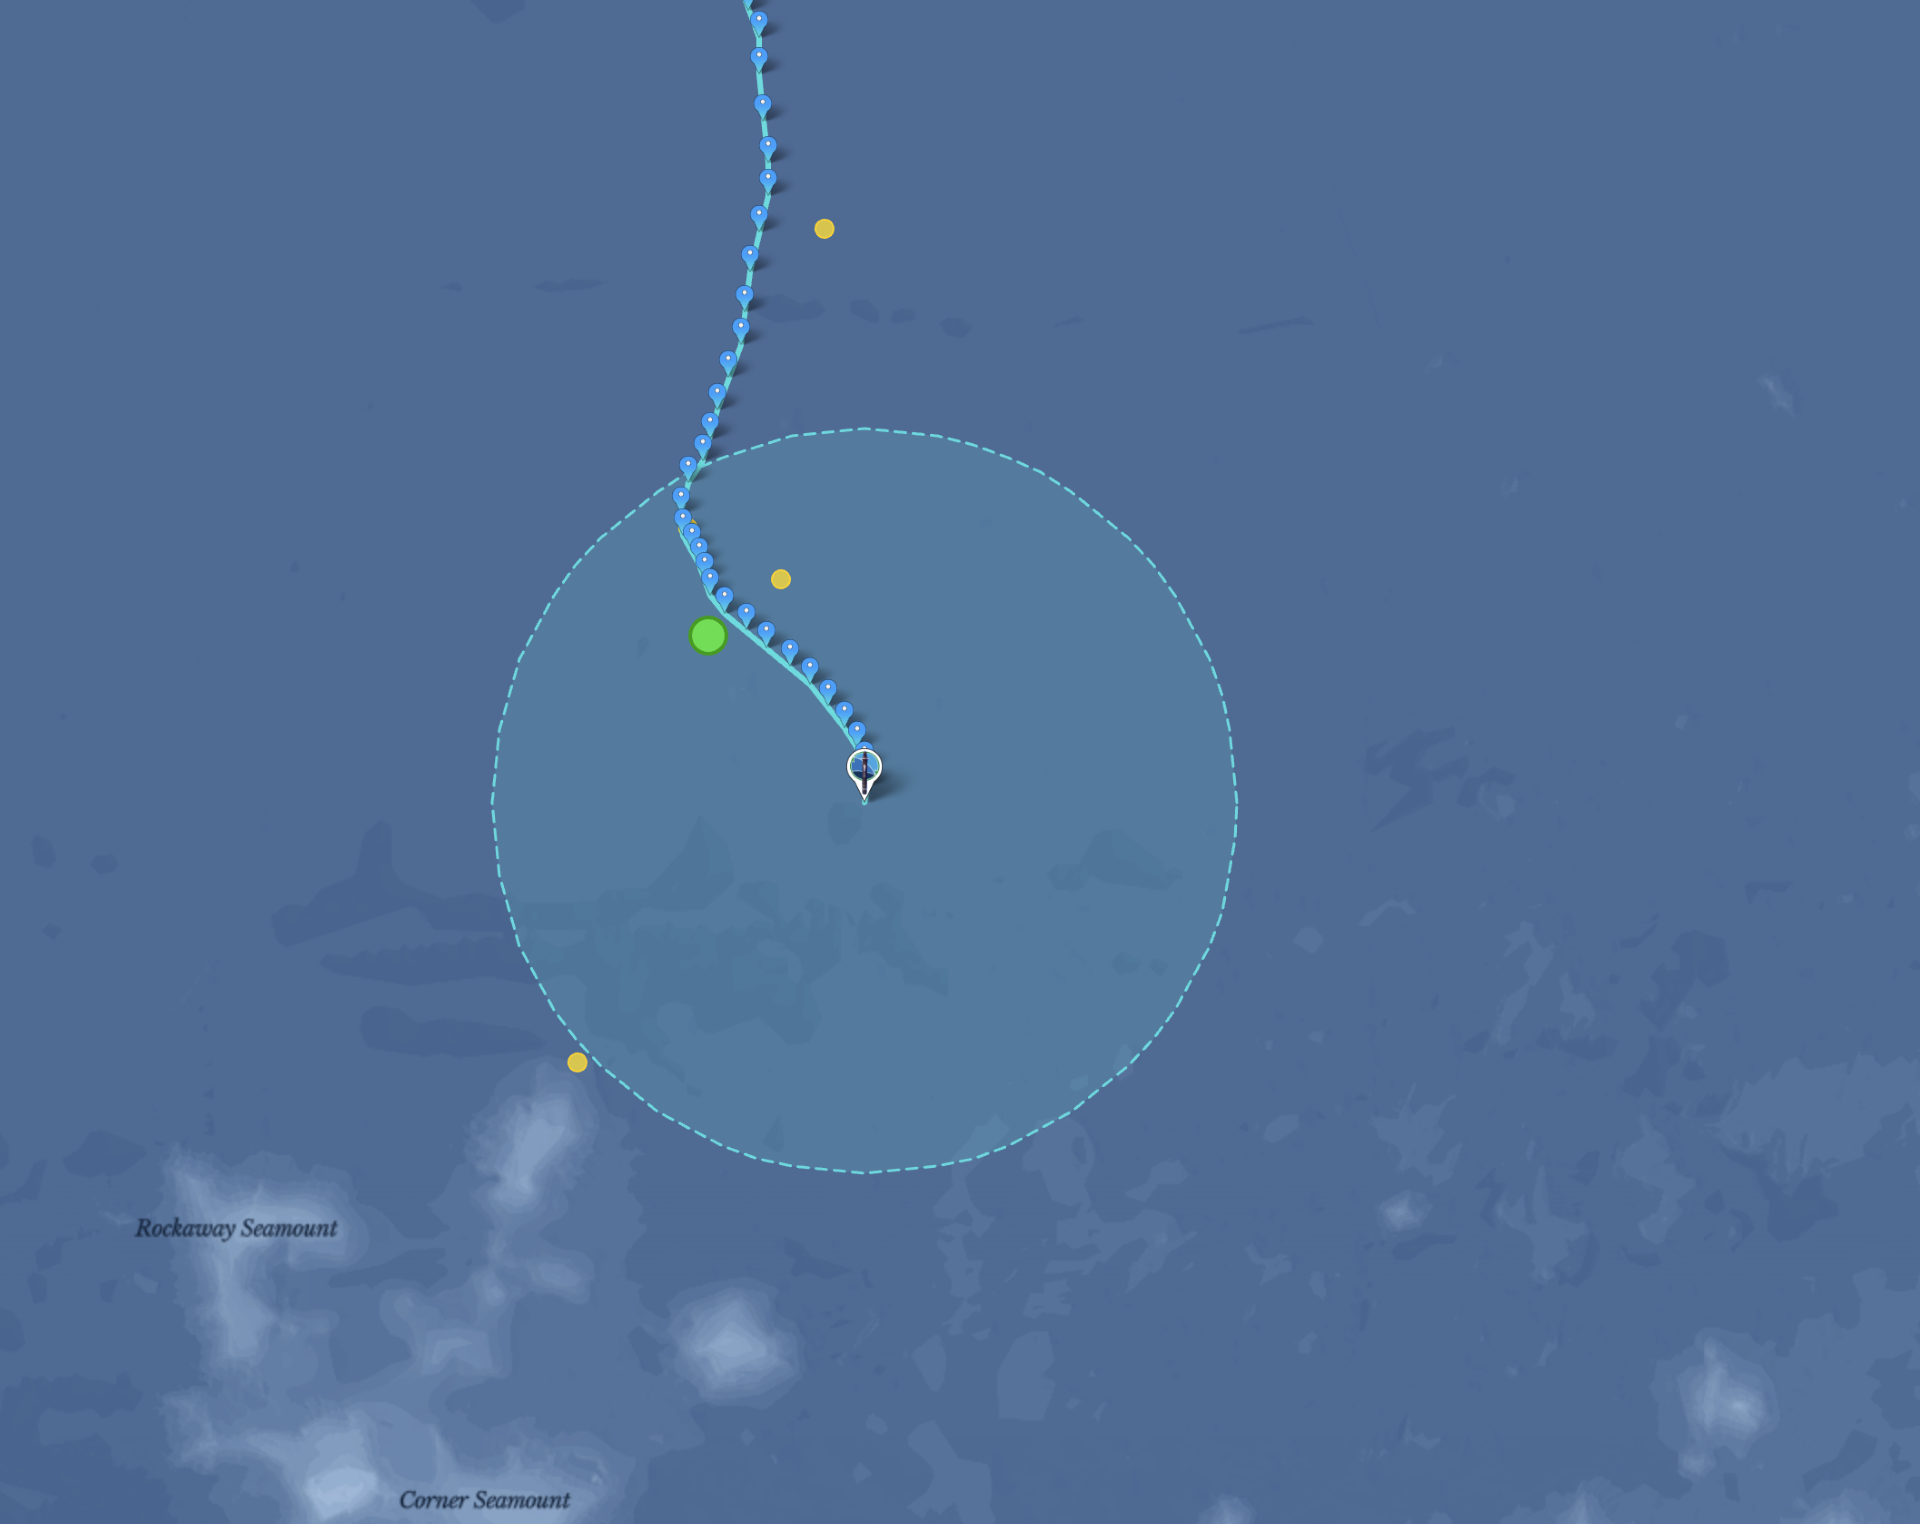
José Manuel’s prediction (green) landed closest of all, with three more entries (yellow) also within 100 km — a genuinely tough target to hit. The rest of the yellow dots, spread across the map, show just how far the ocean can carry even a well-researched prediction.

The field made it a real race. Entries came in from around the world, and only four landed within 100 km of The Monk’s surfacing position — José Manuel’s the closest among them. Between them, the top four spanned Mexico, France, and both coasts of the United States — and all four are expert oceanographers.

Every entry, ranked by distance. Only four predictions worldwide landed within 100 km.
03The Winning Prediction
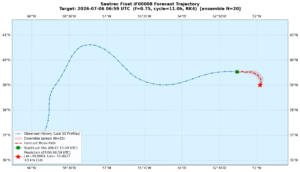 José Manuel’s prediction graphic.
Oceanographers describe moving water in two ways. The Eulerian view watches the ocean from fixed points, like a moored buoy reporting the current flowing past it, or a weather station reporting the wind. The Lagrangian view follows the water itself, like a message in a bottle going wherever the ocean takes it. Predicting The Monk is a classic Lagrangian problem: the float is a kind of diving bottle, and the question is where the ocean carries it.
That is what makes it hard. A Lagrangian forecast has to get many things right at once, and an error in any one of them can grow day by day:
- The mean current — the Gulf Stream is a geostrophic current, driven by sea surface height gradients, that can advect a float over 100 km a day in its core and far less just outside it. Get the current’s strength or position wrong and the whole trajectory shifts.
- Mesoscale eddies — warm-core and cold-core rings, tens to hundreds of kilometers across, that pinch off from meanders in the main current. A float caught in one gets trapped in rotational flow instead of advecting downstream — you can see exactly this looping behavior in The Monk’s track.
- Meanders — baroclinic instability makes the Gulf Stream snake rather than flow straight; whether a given meander sweeps the float north or south of the mean path can matter by hundreds of kilometers.
- Vertical shear — a profiling float spends much of its time below the surface, where current speed and direction can differ substantially from the surface, so the model has to resolve the current field at depth, not just at the surface.
- Chaotic dynamics — Lagrangian trajectories are sensitive to initial conditions; small position uncertainties amplify over time, the same underlying reason weather forecasts lose skill with lead time. A few kilometers of error early on can compound into a much larger miss days later.
- Data latency — position updates stopped on June 28; the prediction target was July 5. That’s seven days of dead reckoning, forecasting motion with no fresh GPS fix to correct against.
For me, it was like a fun programming exercise to also test the methodologies I use as part of my Ph.D.
— José Manuel Echevarría Rubio
A note for any Gen-AI submissions: the four closest entries came from oceanographers; AI-assisted guesses landed about six times farther out. The ocean is a complicated system! Join our webinar on August 18 and learn how the humans did it.
04The Interview
|
▶ CaTCH AN INSIGHT We met with José Manuel to talk about his prediction, his research, and the ocean itself. He’ll be sharing more during a webinar scheduled for August 18th. |
A QUICK SNIPPET BEFORE THE ACTUAL WEBINAR → |
What made you enter Where’s the Monk?
I saw the LinkedIn post, and part of my PhD thesis is modeling the Lagrangian transport of pelagic sargassum.
Walk us through your approach — what data and models did you use?
First, I got the whole track of the float since its deployment in the Gulf of Mexico. I used Copernicus Marine data — the Global Ocean Physics Reanalysis (GLORYS) current fields — with eight depth levels from the surface down to about 900 meters and built a cube of currents. I modeled the float’s trajectory going down into the deepest layer and back up to the surface every 11 hours, at about 0.1 meters per second for the descent and buoyant ascent rate.
I used two different datasets: a reanalysis for the hindcast (past ocean current data) and a forecast product for the actual prediction — which has more uncertainty, so I had to build an envelope of possible trajectories rather than a single path. I ran the simulations using the OpenDrift library, developed by the Norwegian Meteorological Institute. To validate the model, I did a grid search to tune all the parameters against the float’s own past positions (hindcast) before generating the forecast — the same validation approach I use in my PhD work with in-situ drifters for sargassum transport.
What was the hardest part of the prediction? What almost threw you off?
I had to use two different datasets — a reanalysis for the hindcast, the past ocean current data, and a different forecast product for the actual prediction. The forecast has uncertainties; it’s not as accurate, so I had to build an envelope of all the possible trajectories and adjust parameters accordingly. That was the trickiest part.
But it was a good exercise, because it’s the same approach I’m using right now to forecast the date and location of the sargassum beaching events.
The Monk surfaced 52 km from your coordinates. What did you get right?
I followed a good methodology — it wasn’t a lucky guess.
What first drew you to oceanography?
I grew up two blocks away from the Caribbean Sea, and the ocean has always been part of my life. My cousin, who is like my sister, studied marine biology and worked at the National Aquarium in Havana (now a Professor of Marine Science in Spain). I went to the Aquarium frequently with her, and she was the one who introduced me to this field of science.
You’re working on your dissertation — what’s it about, and what’s next for you?
My dissertation is on the factors that are controlling the proliferation of sargassum in the equatorial Atlantic — known as the Great Atlantic Sargassum Belt. First, I need to detect the sargassum, calculate the coverage, and simulate the trajectories. And the final part of my PhD is to try to find what is driving the blooms. Looking ahead, I want to stay right at that intersection, continuing to work on projects that combine remote sensing with ocean modeling to solve complex environmental challenges.
Any advice for people entering the next contest?
The first advice I’ll give is to have a solid ground truth — the past track the float actually took — and validate your model against that in-situ data before you attempt a forecast. Try to do the validation first. I do a lot of machine learning too, and it’s the same principle: you train your model, then validate on data the model hasn’t seen before
Plans after your dissertation defense?
I want to do a postdoc, maybe at the same institution — I’m not sure yet, but for sure I want it to combine remote sensing and physical oceanography. I’ve worked a lot with remote sensing already; for example, I did a project researching kelp forests on the West Coast, in the Pacific Northwest, and I really love kelp forests and the role they play in coastal ecosystems. I want to continue working on combining remote sensing with physical oceanography and ecological modeling. The first advice I’ll give is to have a solid ground truth — the past track the float actually took — and validate your model against that in-situ data before you attempt a forecast. Try to do the validation first. I do a lot of machine learning too, and it’s the same principle: you train your model, then validate on data the model hasn’t seen before
05What’s Next
José Manuel takes home the exclusive Seatrec “Infinite Energy · Deeper Insights” infiniTE™ T-shirt — and he’s not done. He’s going to compete in the next contest, and on Tuesday, August 18, 2026, at 9:00 AM PDT, he’ll join Dr. Paul Chamberlain, Postdoctoral Researcher at Scripps Institution of Oceanography, for our webinar “Finding The Monk: How to Predict Where the Ocean Takes a Float” — a walkthrough of real trajectory-prediction techniques, including how the winning forecast came together. José Manuel will defend his Ph.D. thesis early August, and by the time of our webinar, he will be Dr. Manuel.
The Series Continues
The Monk is Continuing its Journey
Our next contest is live. Same float, new currents, new prediction, new chance to win.
|
Mission Brief The Monk is drifting.On June 23rd, the Monk was at 39.1239°N, 55.4052°W — carried by currents, thermoclines, and the physics of the deep. |
01The Challenge
Somewhere in the North Atlantic, a profiling float named "The Monk" is drifting — guided by currents, thermoclines, and the physics of the ocean. It's one of Seatrec's infiniTE™ floats, powered by thermal energy harvested from the temperature gradient between warm surface waters and the cold deep.
We know its last confirmed position. What we don't know — and what we're asking you to figure out — is exactly where The Monk will surface on July 5, 2026 at 11:59 PM PDT.
No hints. Just your read of the ocean, or your most inspired guess. Use the live tracker to study its trajectory. Dig into Gulf Stream data. Or go with your gut. Closest guess wins — ties broken by earliest submission.
Contest Brief
|
📍 Last Confirmed Position ON 6/23/26 39.1239°N, 55.4052°W ⏰ Contest Deadline July 5, 2026 · 11:59 PM PDT |
🔍 Track Live 📅 Position Updates REVEALED Until June 28, 2026 · 11:59 PM PDT |
02What Is the infiniTE™ Float?
The infiniTE™ is Seatrec's flagship ocean profiling float, designed to operate autonomously for years without battery replacement — harvesting energy from the ocean's natural temperature gradient to power itself and collect critical oceanographic data on every dive cycle.
The Monk has been tracing the currents of the Atlantic, and its track tells a story of eddies, meanders, and the Gulf Stream system. Where it ends up next is yours to predict.
🏆
Win the Exclusive Seatrec T-Shirt
The winner receives this exclusive Seatrec "Infinite Energy · Deeper Insights" infiniTE™ T-shirt — limited edition, not for sale.
One Winner · Closest Coordinates Wins
03How to Enter
|
STEP 01 Study the trackerWatch The Monk's trajectory at the live tracking link. Positions update through June 28, 2026 · 11:59 PM PDT. |
STEP 02 Make your predictionPick a latitude and longitude for where The Monk will surface on July 5, 2026 at 11:59 PM PDT. |
|
STEP 03 Submit coordinatesDrop your numbers into the official entry form before the deadline. |
STEP 04 Win the shirtClosest entry wins. Ties broken by the earliest valid submission. We'll announce the winner shortly after July 5. |
04Coming Soon: Float Modeling Webinars
Seatrec will be hosting webinars on real float-modeling techniques — ocean current analysis, Argo float data, and trajectory prediction with public datasets. Stay tuned for dates.
Drop Your Coordinates
Ready to Outguess the Ocean?
The Monk is waiting to be found. Closest coordinates win.
Submit Prediction →Open Live Tracker
Contest run by Seatrec. No purchase necessary. Open to residents worldwide, ages 13+. Entrants under 18 must have parental permission. Void where prohibited. Winner contacted by email.
Seatrec Launches Initiative to Boost Cost-Effective Seafloor Mapping
Seatrec Launches Initiative to Boost Cost-Effective Seafloor Mapping by Developing Autonomous Echosounder Float Powered by Ocean’s Temperature Differences
Project funded by Schmidt Marine Technology Partners brings seafloor mapping dream team together with transformative and sustainable tech to map the 80% of ocean bottom still uncharted at high-resolution
VISTA, Calif. (Oct. 27, 2021) – Seatrec, a renewable energy company that harvests energy from temperature differences in the environment, today launches a project to develop an autonomous echosounder float powered by clean, sustainable energy. With funding from Schmidt Marine Technology Partners, a program of the Schmidt Family Foundation founded by Wendy and Eric Schmidt, Seatrec will provide the float and power system while New Hampshire-based Airmar Technology Corporation, in collaboration with Innomar Technologie GmbH based in Germany, will provide the active acoustic echosounder for high-resolution mapping.
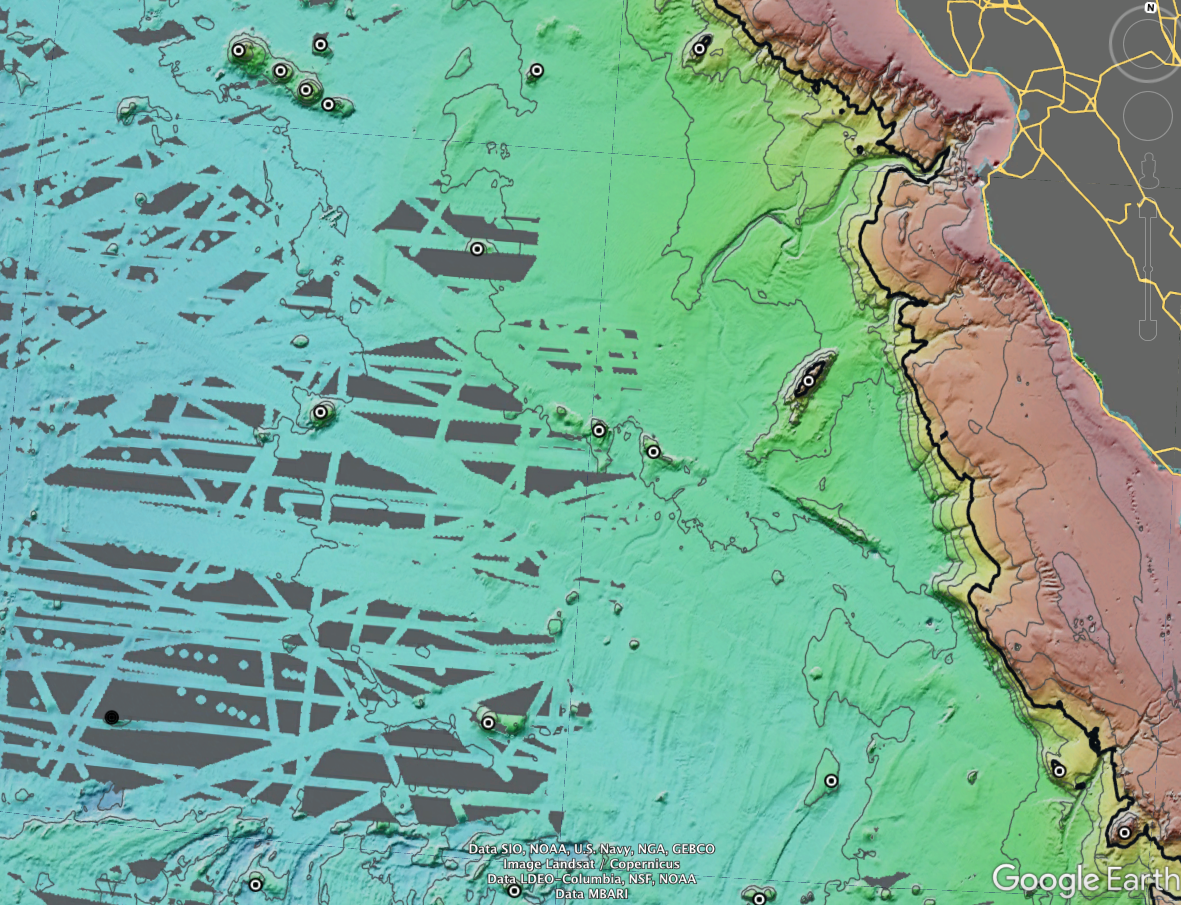
“Eighty percent of the seafloor has not been mapped at high-resolution - an area roughly twice the size of Mars - and covering an area that large using ships and today’s state-of-the-art autonomous platforms will cost billions of dollars,” explains Yi Chao, CEO and Founder of Seatrec. “This initiative brings together a seafloor mapping dream team with the transformative technology needed to create a sustainably powered method for mapping the ocean floor for a fraction of the cost compared to ships.”
The project is led by Larry Mayer, a professor and Director of the Center for Coastal and Ocean Mapping at the University of New Hampshire.
“The ocean’s resources are critical to supporting and sustaining all life on Earth and it’s shocking how little we know about something as fundamental as the seafloor,” observes Mayer. “It’s imperative that we develop the next generation of ocean mapping technologies to support the international community’s unprecedented effort to finally map the seafloor at high-resolution -- there’s no time to lose.”
Indeed, the world is racing to map the seafloor to help manage living resources, improve marine navigation, and guide infrastructure construction, as well as better defining the impacts of current and future human activity. The Nippon Foundation-GEBCO Seabed 2030 Project is a first-of-its-kind international effort to facilitate the complete mapping of the seafloor by 2030 and is a major contribution to the UN Decade of Ocean Science for Sustainable Development (2021-2030).
However, two critical obstacles stand in the way of success: energy and cost.
Mapping the 80% gaps of the global seafloor will cost an estimated $3B using ships burning diesel fuel and emitting carbon dioxide into the atmosphere. A robotic revolution resulted in the growing use of autonomous vehicles to reduce the cost of using ships and the associated carbon footprint. Seatrec’s technology to harvest energy from the ocean thermal energy is transformative and provides a cost-effective and sustainable solution to deploy a fleet of subsea robots at a fraction of the cost of ships.
“Mapping the seafloor provides fundamental and critical data we need to protect the health of our oceans but such a massive undertaking requires innovative and sustainable solutions from the best and brightest,” points out Erika Montague, the Chief Technologist of the Schmidt Marine Technology Partners. “This initiative provides a path forward towards better understanding and protection of our ocean.”
About Seatrec
Seatrec designs and manufactures energy harvesting systems that generate electricity from naturally occurring temperature differences in ocean waters. This renewable energy can be used to power deep water oceanographic research equipment such as floats, gliders, and Autonomous Underwater Vehicles (AUVs), resulting in the most scalable, cost-effective deep ocean data collection possible. Incorporated in 2016 by CEO, Dr. Yi Chao, Seatrec’s technology originated at NASA Jet Propulsion Laboratory, California Institute of Technology, to provide clean power for remote off-grid locations. The company is headquartered in Vista, CA. Visit us at www.seatrec.com and @seatrecinc.
Media contact
Sean Yokomizo
+1 925.878.1200