
Yi Chao on NDIA’s Emerging Tech Horizons

In a special edition of NDIA’s Emerging Tech Horizons, recorded live at the 2026 Emerging Technologies Conference in Washington, DC, Seatrec founder and CEO Dr. Yi Chao sat down with host Mark Lewis. They discussed how Seatrec’s ocean-powered drones went from an idea born at Caltech and NASA’s Jet Propulsion Laboratory to a technology now headed into the hands of the warfighter.
The problem: batteries. We’ve mapped about 99% of the Moon but only about 25% of the seafloor. Underwater sensors and drones run on batteries, and when those batteries die, the choice is to abandon the device or pay for a ship to recover it. That cost limits how much of the ocean we can observe.
The solution: energy from the ocean itself. Seatrec’s floats use a wax-like phase-change material. When a float rises into warmer water, the material melts and expands about 10%. That pressure spins a generator that recharges the battery. The material can be tuned to the waters where a float operates, so energy is no longer the limit.
The path from research to the fleet:
- Basic research at Caltech/JPL, funded by the Office of Naval Research
- Seatrec spins out in 2016 and matures the technology through SBIR and STTR awards
- A Defense Innovation Unit accelerator puts the team in front of INDOPACOM and the Pacific Fleet
- Prototyping funded by the Office of the Under Secretary of Defense for Research and Engineering, plus fleet exercises
- Today: a new contract to deliver vehicles to the Navy and scale up manufacturing in Mississippi, near our Navy and oceanography customers
Our thanks to NDIA and Mark Lewis for the conversation, and to NDIA for its support of the SBIR program.
Read the full transcript
Show: Emerging Tech Horizons special edition, recorded live at NDIA’s 2026 Emerging Technologies Conference, Washington, DC
Recorded: September 2026
Participants: Mark Lewis, host; Dr. Yi Chao, Founder and CEO, Seatrec
Video: Watch on YouTube (this conversation is the first of two in the episode)
This transcript has been lightly edited for clarity (clean verbatim). Timestamps are approximate and link to that point in the video.
[00:03] Studying the ocean from space
Mark Lewis: Welcome to Emerging Tech Horizons. I’m Mark Lewis, and I’m coming to you from the Emerging Technologies Conference 2026, sponsored by the National Defense Industrial Association. In this segment, I’m joined by Yi Chao, who is going to tell us a remarkable story about a technology that has gone all the way from basic research into the hands of the warfighter. To start off, can you tell us a little bit about yourself? Then we’ll talk about this product you’ve been working on and some of its history.
Yi Chao: Thank you for the opportunity. My name is Yi Chao. I’m the founder and CEO of Seatrec. Seatrec is a spinout of Caltech. We were funded by the Navy’s Office of Naval Research to develop this technology to harvest energy from the ocean. I’m an oceanographer. I have a PhD in oceanography and have studied the ocean for 20 years.
Mark Lewis: And you were working at the Jet Propulsion Laboratory.
Yi Chao: I worked for Caltech/NASA’s Jet Propulsion Laboratory, studying the ocean from space. The challenge is that satellites only see the surface. We don’t really know much about what’s below the surface. From the sea surface to the seabed, it’s all unknown.
Mark Lewis: I’ve heard it said that we know more about the surface of the Moon than we do about the bottom of the ocean.
Yi Chao: Very true.
Mark Lewis: Yes.
Yi Chao: Because we have mapped 99% of the Moon and 99% of Mars, but we’ve only mapped 25% of our seabed. Imagine your Google Maps is missing 75% of the roads. Would you be able to drive with that map?
Mark Lewis: That would be a challenge. Understood.
[01:37] The battery problem
Yi Chao: During my NASA career, I ran into these challenges for the Navy and also for ocean research and exploration in general. Underwater sensors and drones are powered by batteries, and these batteries have a limited lifetime. When the battery runs out, you have two options. You let it go, and it becomes trash in the ocean, or you hire a boat to recover them, swap the batteries, and deploy them again. As these drones and sensors drift farther from shore, the farther from the harbor, the more expensive it becomes. At some point, it’s almost more expensive to hire a boat to recover one than to just deploy a new one. That really limits how many sensors we put in the ocean, and that’s probably why we know so little about the ocean. So energy is the biggest challenge, and it’s a challenge the Navy faces as well.
[02:35] How it works
Yi Chao: So I did a study in the library at that time, and I discovered this concept proposed back in 1989 that used a wax-like phase-change material to harvest energy from temperature differences.
Mark Lewis: So it’s a phase-changing material.
Yi Chao: It’s a phase-change material, PCM. It’s like a wax. That particular concept used the wax to melt from solid to liquid, and used the volume expansion to drive the robot moving up and down. I said, that’s a really good idea, but if you don’t generate electricity, you cannot store that expansion. So I worked with two smart engineers at JPL, and the three of us invented a new concept: how about using wax PCM to generate electricity?
When the robot comes to the surface, it moves from cold water to warm water, so the solid material wax melts once it crosses the phase-change temperature. The melted liquid has 10% more volume than the solid, and that 10% expansion generates a huge hydraulic pressure that spins a motor to generate electricity. Once you generate electricity, you can store it in a rechargeable battery. Once the battery is fully charged, you can do scientific missions: data collection, computing, and real-time satellite data transmission.
Mark Lewis: Very clever. Obviously, if it’s undergoing a phase change, it’s going to be temperature sensitive. So do you tune it for the part of the world you’re operating in?
Yi Chao: There’s a family of materials we can pick from, depending on the area of operation. For our Mediterranean customer, for example, the bottom temperature is 14°C. If we pick an 18°C phase-change temperature, that material will generate electricity in the Mediterranean. But a Hawaii customer wants 10°C. So it depends on the area where the drones and sensors are deployed. We just pick the right material with the right phase-change temperature.
Mark Lewis: But it is flexible. Understood.
[04:31] From research to a company: ONR, SBIR and STTR
Mark Lewis: Great. So now tell me the journey of how you got from what sounds like a basic research concept, through all the various levels in the Department, to get it into operation. What are the steps you followed?
Yi Chao: We developed the prototype under the ONR contract.
Mark Lewis: That’s the Office of Naval Research, which sponsors basic research work for the U.S. Navy.
Yi Chao: That’s correct. They contracted Caltech to develop this prototype, and we had two patents granted to Caltech. We had a prototype deployed in the ocean for 18 months, completing 1,000 profiles from the surface to 1,000 meters. So for the first time, we had an underwater drone completely powered by the ocean.
Mark Lewis: When was the ONR part of this?
Yi Chao: That was more than 10 years ago, about 12 years ago. Then about 10 years ago, Seatrec spun off from Caltech. I decided to quit my job to start Seatrec. I had two patents granted. I had a prototype. How hard could it be to get it commercialized?
So basically, I started Seatrec 10 years ago, in 2016. We just celebrated our 10-year anniversary. After we spun out, we continued to get SBIR (Small Business Innovation Research) money to help us through the commercialization process. We also got an STTR.
Mark Lewis: I want to come back to the SBIR process. The SBIR program is an amazingly powerful program. And you start with Phase I.
Yi Chao: We started with Phase I.
Mark Lewis: Which is relatively modest funding.
Yi Chao: Phase I is a small amount of money for paper studies and laboratory studies. Then we got a Phase II SBIR, working with industry and academic institutions to continue maturing the technology. We had Phase II, and then even a Phase II option. And eventually we got an STTR to work with the Woods Hole Oceanographic Institution.
Mark Lewis: An STTR is very much like an SBIR, but you have to involve…
Yi Chao: More participation from a research organization. It allows us to work with researchers and professors.
Mark Lewis: Again, an amazing program that helps bring ideas out of the research laboratory at, say, a university, into industry, and then ultimately into a product.
Yi Chao: It’s critical for a small startup without a lot of private equity capital. Many early startups fail because they probably raise too much capital before the product matures, and the timescale for equity investment to see a return on investment is very short, so you need to go really fast. A lot of maritime and ocean tech takes longer.
Mark Lewis: Right.
Yi Chao: The ocean is very challenging. The experimental cycle is very long. You have to deploy and test, and then recover, and then analyze.
Mark Lewis: Right.
Yi Chao: So it’s much longer than software, much longer than consumer products. This is deep tech, maritime tech, so it just takes longer. Having SBIR and STTR to reduce that risk before we bring investors in is critical. We have raised small amounts of private capital, but SBIR and STTR are the main vehicles.
Mark Lewis: I’m going to put in a plug here, because we’re at the National Defense Industrial Association conference. NDIA was actually instrumental in getting the SBIR program reauthorized.
Yi Chao: Thank you.
Mark Lewis: So a shout-out to the SBIR. When I worked for NDIA, my colleague Kea Matory led that effort and explained to Congress the importance of the program. Efforts just like yours really shine a light on what the SBIR portfolio can do.
Yi Chao: Thank you for that support! You enabled us to be successful.
Mark Lewis: NDIA, yes.
[08:30] Meeting the warfighter
Mark Lewis: So you go through the SBIR phases. What came next?
Yi Chao: Then we launched our commercial product about four years ago. That was in the middle of COVID, so we did limited sales to the research market, mainly universities and NGOs. About three years ago, I participated in the NSIN Accelerator (National Security Innovation Network).
Mark Lewis: From the Defense Innovation Unit (DIU).
Yi Chao: From DIU, NSIN Propel Hawaii. It’s essentially an incubator. They brought 12 startup companies like ours and three maritime companies into a six-month program that gave us access, primarily, to INDOPACOM and the Pacific Fleet. And the highlight of the program was attending the POST Conference for free.
Mark Lewis: Which is sponsored by…
Yi Chao: NDIA.
Mark Lewis: You’re all seeing a theme here.
Yi Chao: Basically, 12 companies crammed into two booths. Everybody had a little corner to show off their technology. It was really eye-opening to talk to the customers, the warfighters walking by. The POST conference has 2,000 people attending, and half of them are in uniform, coming from different units across the Indo-Pacific and from the Pentagon as well. So for the first time, I was able to learn about the needs, the gaps, and the requirements. That’s really eye-opening for a startup like ours, to say, “OK, I can fill this gap. I can meet these requirements.” The second year, I was able to rent a booth. I saw the value, so the second year I came back to NDIA.
Mark Lewis: Excellent.
Yi Chao: I reserved a small booth for ourselves and did a display. That’s where I met Under Secretary Heidi Shyu. This was three years ago. She asked all the right questions, and she introduced me to her office and Alex Lovett’s office. For the first time, I had a meeting in the Pentagon with Dr. Tran to understand the R&E programs. Then we got funding from the Prototyping and Experimentation Team in R&E for a rapid prototyping project. They bought an initial fleet of three to five units, and we started taking them to exercises. We were in Black Widow with the Pacific Fleet two years ago; we were in T-REX; and we were in the U.S. Virgin Islands, working with Dr. Alexander’s assessment team. And we’re going to do more experiments with Dr. McAllister’s experimentation team. So we are maturing the system, trying to understand where it works well and where we need improvement.
Mark Lewis: I love that story, because first, it involves our basic research investments, which are absolutely critical to advancing knowledge. They flesh out the idea, and then it gets handed off through the SBIR and STTR programs. Then it goes to the Defense Innovation Unit, which is an amazing organization that, as its name implies, is trying to get innovative ideas into the hands of the warfighter. Then you go to POST and meet with the J8, the folks who do the technology development and requirements for INDOPACOM. And by the way, my feeling has always been that INDOPACOM leads in understanding the value of innovative technology, because they have so many challenges in that particular region.
Yi Chao: Yes. For example, I met Bob Stevenson at the POST conference. He was walking around. He gave a keynote. He’s the director of the J8 and requirements, and he saw the value of this technology for their requirements to be met.
Mark Lewis: Yes. And then the Under Secretary of Defense for Research and Engineering steps in with prototyping, and we get to a capability. Phenomenal story.
[12:25] Scaling up
Mark Lewis: So where are we today? Tell us about what you’re doing today.
Yi Chao: Two months ago, we signed a contract for APFIT, so now we are ready to scale up. In addition to the exercises and the ongoing improvements we’re doing, we are ready to transition. The APFIT award we signed two months ago allows us not only to deliver this vehicle to the Navy this calendar year, but also to immediately deliver to different COCOMs, to the Navy, to the Naval Oceanographic Office, and to the Naval Meteorology and Oceanography Command (CNMOC), so they get access to the tools, the sensors, and the data immediately. So we have three years to also scale up our manufacturing.
We identified Mississippi as the site to manufacture our devices.
Mark Lewis: Why Mississippi?
Yi Chao: Because the Naval Oceanographic Office, the Naval Research Laboratory (NRL), and the Commander, Naval Meteorology and Oceanography Command are all at Stennis Space Center. So it all makes sense. Our direct customers are in Mississippi, with thousands of people working at Stennis Space Center. We want to be closer to our customers, so they can come to us to ask questions, we can do training, and we can go to them for meetings and participate in person. A lot of that communication and dialogue will help us understand their needs better.
So we are ready to scale. We are based in San Diego, and we’ll continue to keep San Diego as our commercial research facility and headquarters, where we’ll develop the next generation. And we’re going to do a lot of the Navy manufacturing in Mississippi.
[14:18] Energy and cost
Mark Lewis: Obviously, having something that can run, and I assume it can run almost forever, right?
Yi Chao: In theory, energy is no longer the limitation. The ocean is a very rough environment.
Mark Lewis: There’s a lot of energy in the ocean.
Yi Chao: There’s a lot of energy. So basically, we take energy out as the limitation.
Mark Lewis: So instead of a couple of hours, maybe a couple of days, we’re now into lifespan. How does cost factor into that?
Yi Chao: When I wanted to develop the commercial product, cost was a challenge, because the first prototype cost $3 million.
Mark Lewis: Right. But the first unit is always the first unit.
Yi Chao: Yes. Then we built our first commercial prototype for about $300,000, so we got an order of magnitude. But that’s still pretty expensive. Even the Navy doesn’t want to lose them. So I decided to set a target for my engineering team: let’s price this at $50,000. $50,000 is one day of ship time. If you decide to collect data by sending an instrument down, a day on a commercial vessel is $50,000, and for the Navy it may be $100,000. So we set $50,000 as the base price, and once you populate the sensors, maybe $100,000 on average. But that’s basically one day of ship time, and you’re going to collect data for three years. Now you can deploy a fleet of these, get spatial coverage of any area of responsibility (AOR), and collect data 24/7 with persistent monitoring.
Mark Lewis: Outstanding. Great. Well, thank you so much for sharing this story with us.
Yi Chao: Thank you for the opportunity.
Mark Lewis: Remarkable story. Congratulations on such a successful effort, and enjoy the rest of the conference.
Yi Chao: Thank you. It’s a great conference here. I’ve met a lot of people. Thank you for the opportunity.


Webinar on Finding the Monk Contest (How to Predict Where the Ocean Takes a Profiling Float)
01Finding The Monk: The Webinar Recap
Last week Dr. Paul Chamberlain of Scripps Institution of Oceanography co-hosted a Seatrec webinar with the winners of our first two Where’s the Monk? trajectory-prediction contests, walking through the actual science — and, by their own admission, the actual luck — behind forecasting where a drifting ocean float will surface, days out, with no fresh GPS fix to correct against. If you missed our winner write-ups, catch up here: José Manuel Echevarría Rubio, Round 1 and Knut-Frode Dagestad, Round 2.
02The Challenge, Recapped
The Monk is an infiniTE float — Seatrec’s patented ocean-thermal-energy-harvesting profiler, out testing in the Atlantic and the Gulf of Mexico. Since deployment, it has logged more than 300 days at sea, completed over 700 dive profiles, and covered more than 7,000 kilometers, diving roughly every 11 hours down to an average parking depth near 900–960 meters before resurfacing just long enough to transmit its position.
Seatrec co-founder Yi Chao had the idea to turn that into a community challenge: give participants the float’s last confirmed GPS fix and its full historical track, then ask them to predict where it would resurface roughly nine days later — no peeking in between. The team named the float “the Monk,” partly for its solitary life at depth, and partly as a nod to oceanographer Walter Munk.
Round 1 drew 24 entrants; only four landed within 100 km of the true surfacing position, and José Manuel Echevarría Rubio won with an error of just 52 km, with an honorable mention to Ruoying (Roy) He and the Fathom Science team at North Carolina State University, whose prediction also landed within 100 km — along with two other entrants. Round 2 was a tighter finish: three predictions landed within 100 km, and Knut-Frode Dagestad of MET Norway took it by just 61 km, with honorable mentions to Liesvy Valladares Alfonso (CICIMAR-IPN) and Zach Dubroc (Mississippi Coding Academies).
03Why Is This So Hard? The Physics of a Growing Error Bar

Paul opened by framing the question everyone was really asking: if you drop something in the ocean and track it for a week, why is 50+ km of error the good outcome? His answer came down to where the uncertainty comes from — and it changes character over time:
- Early on (the “ballistic” regime): uncertainty grows roughly in proportion to time — small early errors in current velocity compound quickly.
- Later (the “diffusive” regime): uncertainty grows more slowly, in proportion to the square root of time, as the trajectory effectively randomizes.
- Over the longest horizons: any systematic bias in the ocean model re-asserts itself, and error growth goes linear again.
Layered on top of that: ocean models like Copernicus GLORYS product and NOAA’s HYCOM typically resolve currents only down to a handful of kilometers — but real ocean motion includes sub-mesoscale eddies, internal waves, and wind-driven variability at scales models simply can’t see. And because profiling floats spend most of their life at depth rather than at the surface, predicting them means resolving the full three-dimensional current field, not just what satellites can observe from above.
“The choice of advection scheme, time step, and interpolation method all measurably shift a predicted trajectory — there’s no single ‘correct’ way to integrate a drifter forward, only trade-offs.”
— Dr. Paul Chamberlain
04Round 1: How José Manuel Won

José Manuel, a PhD candidate at CICIMAR-IPN studying sargassum transport in the Atlantic and Caribbean, adapted tools he already uses for tracking surface drifters to the Monk’s much deeper problem. Because the Monk spends more than 98% of its time below the surface, he built a three-phase dive model — roughly 30 minutes at the surface to transmit, a ~2.5 hour descent at 0.1 m/s, and around 7.5 hours parked near the deepest point of its dive (about 900 meters) — and sampled ocean currents at each phase separately, rather than assuming one depth for the whole trajectory. He discarded surface wind/wave (Stokes) drift entirely once testing confirmed it had no meaningful effect, since the float spends so little time at the surface.
Using Copernicus’s global Mercator current product (~9 km resolution, 8 depth levels) and OpenDrift for the simulation, he scored candidate configurations with the Liu–Weisberg skill score and ran a grid search (via scikit-learn) tuning a current “slip” coefficient and the length of the re-initialization window. His best setup — a 7-day reinitialization window and a current coefficient of 0.75 — produced a mean skill score of 0.96 across the float’s full 284-day history at the time (1.0 being a perfect match), and it’s what won him Round 1 with 52 km of error.
“You have to actually resolve the vertical dive cycle — not just the horizontal drift — to get this prediction right.”
— José Manuel Echevarría Rubio
His own lessons learned: the vertical dive cycle matters as much as horizontal current speed, shorter reinitialization windows keep errors from compounding, and trustworthy skill metrics matter more than chasing any one lucky-looking result.
05Round 2: How Knut-Frode Won — and What His Colleague’s Research Adds

Knut-Frode, lead developer of OpenDrift, found the contest post on LinkedIn just two days before the Round 2 deadline and built his entry solo, in what he candidly called an “embarrassingly simplistic” version of José Manuel’s approach. He pulled the float’s historical track into Trajan (a standalone Python trajectory-analysis package originally built inside OpenDrift, now spun out so it can score any drift model’s output against observed tracks), then tested his simulation against the real historical positions. His first pass — surface currents only — performed poorly, as expected, since the Monk spends almost no time at the surface. His second pass, holding the float at a single eyeballed depth of 700 meters (versus José Manuel’s calculated ~900–960 meters), tracked the real trajectory far more closely, and that’s the current field he ultimately trusted for his forecast.
Rather than over-engineer it further, he made a judgment call: since forecast errors compound regardless of method, and Round 2 had fewer entrants than Round 1, the odds favored a good-enough model over a heavily-tuned one. He was open that part of this was a bet on variance:
“It’s a little bit like playing poker — in a single game, anyone can win, but in the end the winner is the one with the best strategy. We hope to do something more robust next time.”
— Knut-Frode Dagestad
His MET Norway colleague Jean Rabault joined to share related bias-correction research from an earlier DARPA ocean-prediction competition: combining multiple current products — satellite-derived (like Globcurrent) and model-based (Mercator, HYCOM, OSCAR) — with a simple linear regression outperformed any single product by 30–40% on the Liu–Weisberg skill score. A neural network trained on the same inputs didn’t beat the linear model, suggesting the individual products’ errors are already close to a fixed offset rather than a complex nonlinear relationship. On ensemble modeling more broadly: the best-performing ensemble member tends to stay best for only the next 1–2 days, but a bad member tends to stay bad for 7–10 days — making it more valuable to filter out consistently poor members than to chase the single best one.
06From the Q&A, and What’s Next
Is the deep ocean less chaotic than the surface?
Javier Zavala-Garay asked how dispersive currents are at 500–1,000 meters compared to the wind-driven surface layer. José Manuel’s view: deeper water masses are more thermally homogeneous and likely less stochastic than the surface mixed layer. Paul pointed to the DIMES experiment — which acoustically tracked floats in the Antarctic Circumpolar Current — as real-world evidence that meaningful current variability exists at depth too, even if it behaves differently than surface turbulence.
Could Lagrangian Coherent Structures help?
Sebastién Legrand raised the idea of using LCS/attractor analysis to flag when a trajectory is entering a region likely to bend a prediction off course. Knut-Frode had experimented with this before and wasn’t convinced it adds much beyond what a good drift simulation already captures — but was open to being wrong about it.
What’s the single easiest next improvement?
Both winners agreed: more complete dive-cycle metadata from Seatrec — exact time-at-surface and time-at-depth per dive — would sharpen everyone’s models. Yi Chao acknowledged that data exists but isn’t well surfaced today, and committed to publishing it more clearly for future rounds.
Looking ahead, Seatrec plans to run the Monk contest on a monthly cadence (weekly proved to be too much of a good thing), likely featuring a different float and location next round. Prizes escalate with repeat wins too — from a t-shirt, up to a jacket, up to a Seatrec cooler bag for anyone who takes the top spot three times. A well-earned congratulations to both winners — and a special shoutout to José Manuel, who successfully defended his PhD dissertation just two days after this session.
Join the Next Contest
Predicting Float Trajectories
Follow Seatrec for the announcement of the next contest and webinar.

We have a Winner! Where's the Monk Contest: Part 2

01We have another Winner!

Meet Knut-Frode Dagestad, our second Where’s the Monk winner — a senior researcher at MET Norway (Norwegian Meteorological Institute | Meteorologisk institutt) who landed the closest guess of all: just 61 km from where The Monk actually surfaced on July 20, 2026.
But he didn’t just predict The Monk’s position — he helped build the tool that made it possible. Knut-Frode is a co-developer of OpenDrift, the trajectory-modeling framework our first winner, José Manuel Echevarría Rubio, used to win the contest. The two have never met, or even spoken — Knut-Frode only learned of the connection when José Manuel’s LinkedIn post about the win crossed his feed.
02The Results
This round came down to a tight finish: three predictions landed within 100 km of The Monk’s actual surfacing position. Knut-Frode’s guess placed him closest of all — just 61 km out. Honorable mention goes to Liesvy Valladares Alfonso, a Physical Oceanographer and PhD Candidate at CICIMAR-IPN (Centro Interdisciplinario de Ciencias Marinas, Instituto Politécnico Nacional) in La Paz, Baja California Sur, Mexico, whose prediction also landed within 100 km — the very same institution as our first contest’s winner, José Manuel Echevarría Rubio. The other honorable mention goes to Zach Dubroc, Instructor at the Mississippi Coding Academies.
03The Winning Prediction
“I only discovered this competition after it was two or three days before the deadline, so I did it — I would say, embarrassingly simple approach. If I had more time, I’d do something more along the lines of what José Manuel did, because he did a much more sophisticated job. But I was in a hurry, so I did it almost primitively.”
— Knut-Frode Dagestad
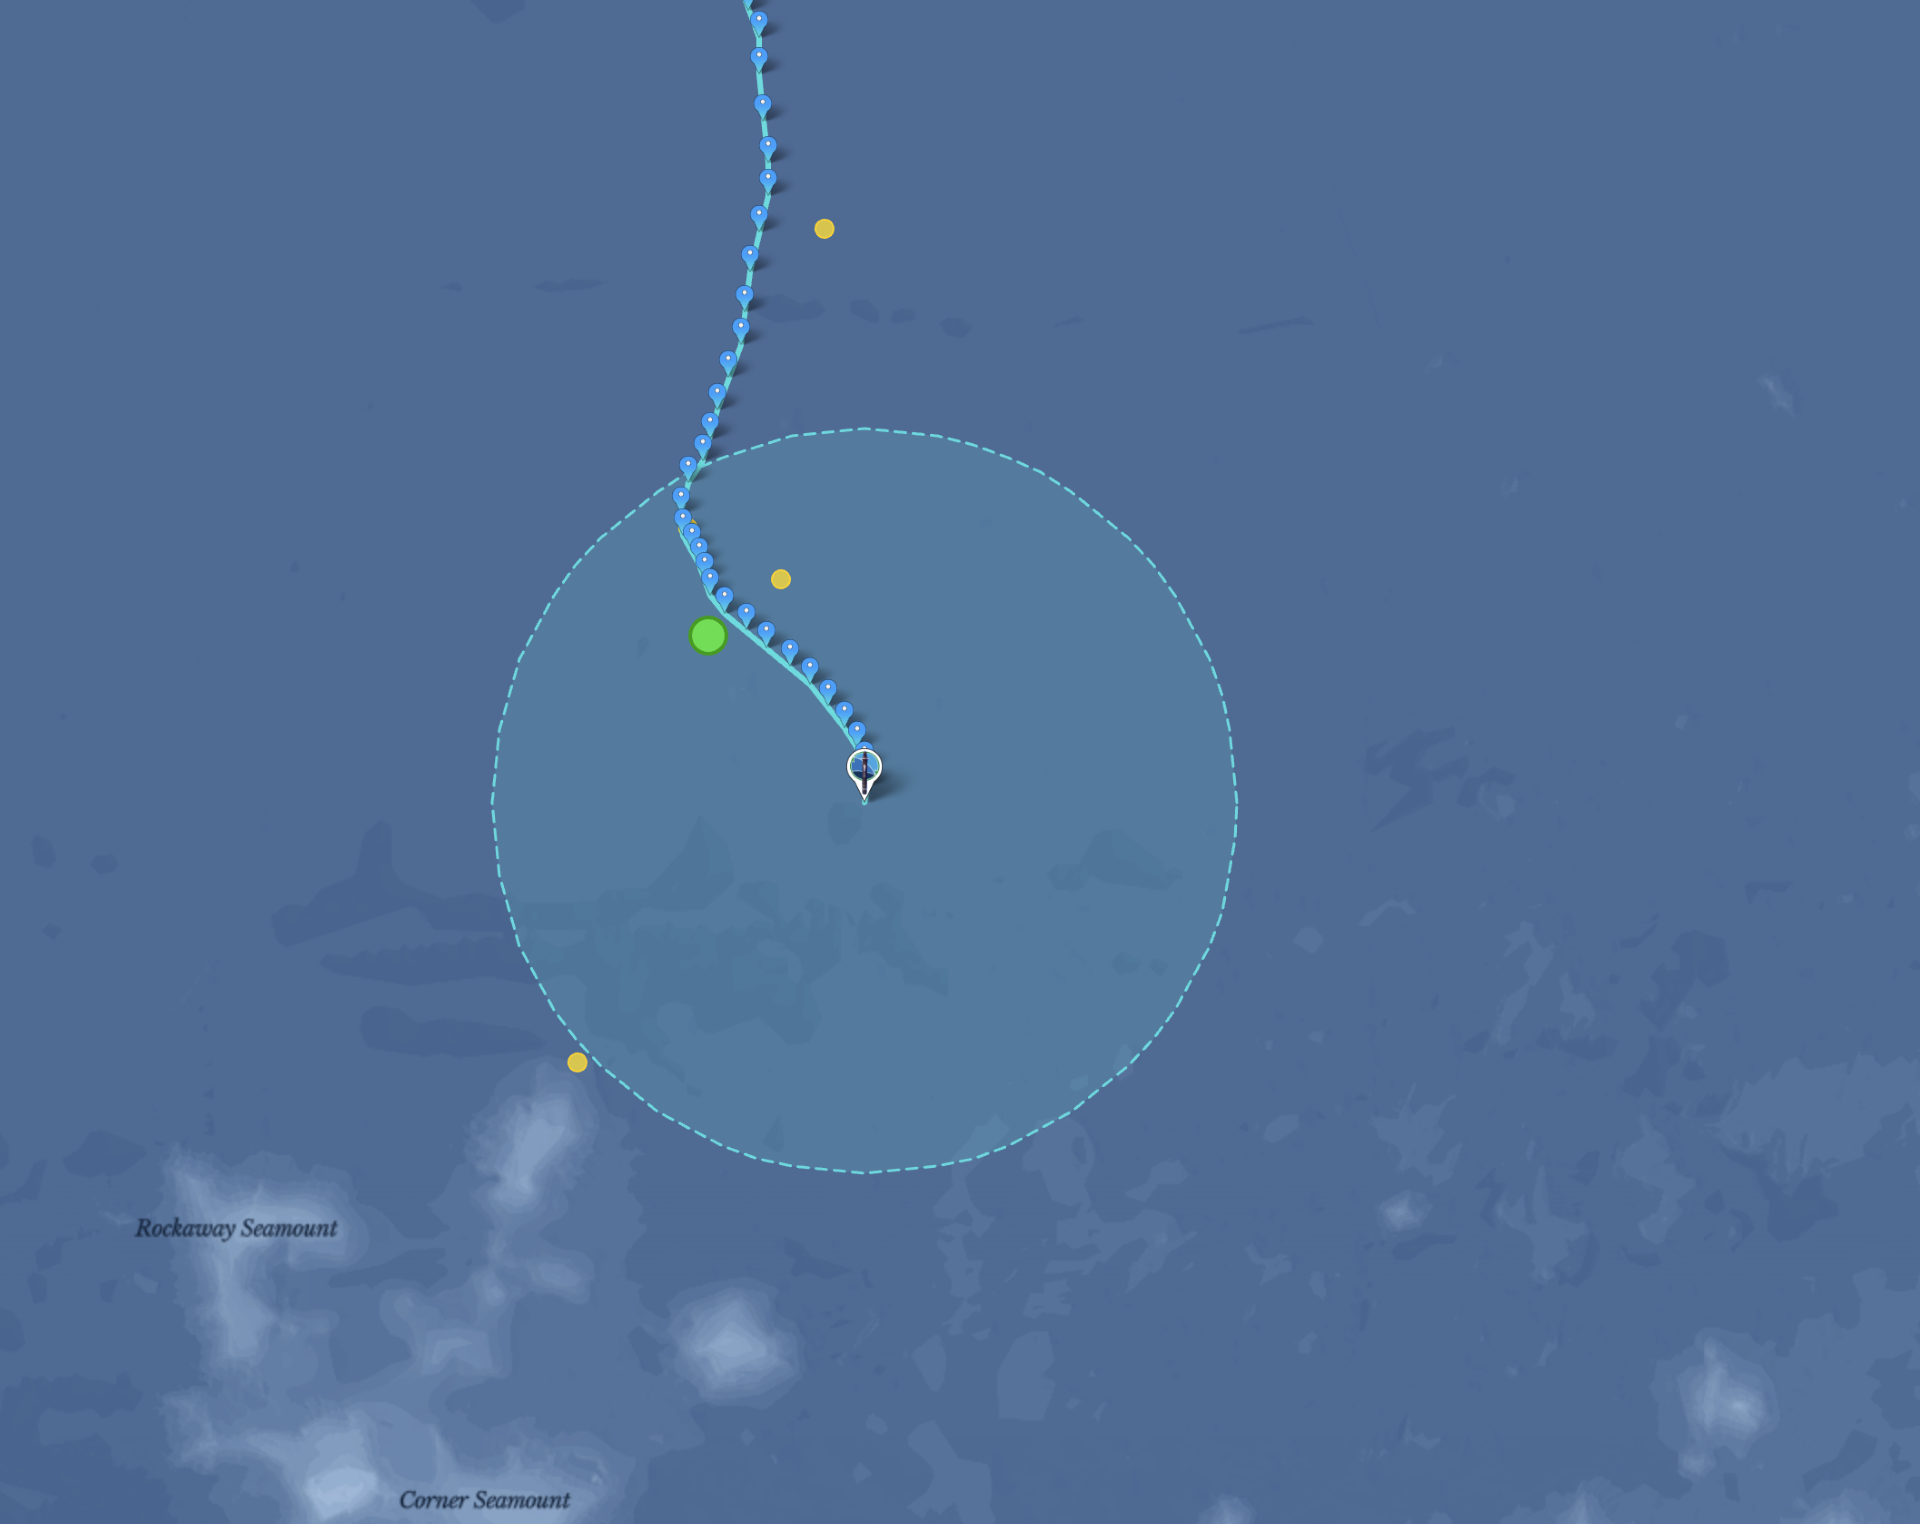
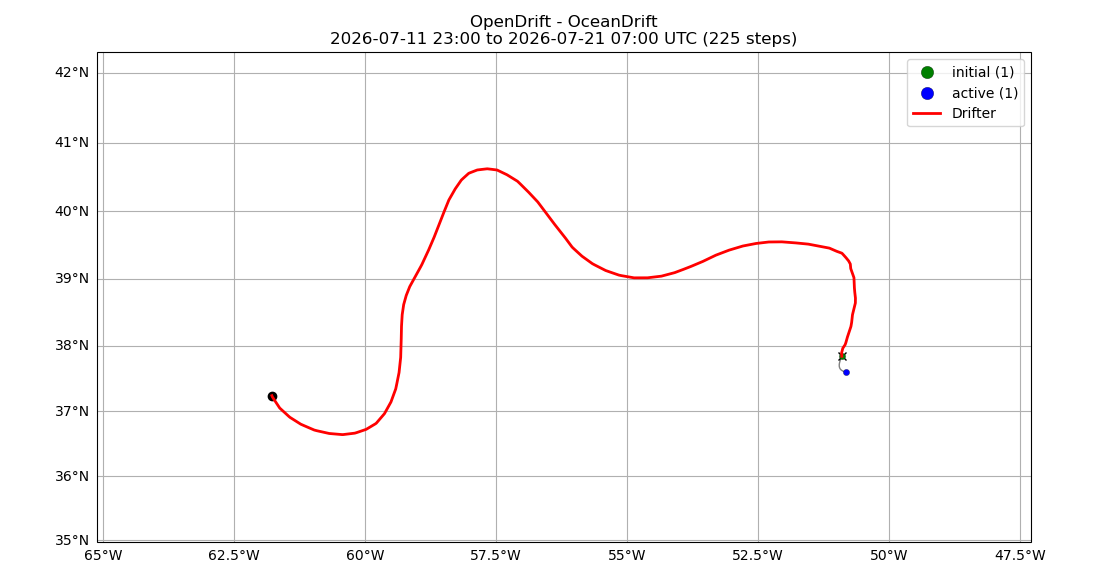
Here’s the forecast he ultimately submitted — run forward from The Monk’s last known position using currents at 700 meters depth, pulled from the Copernicus Marine Service’s Global Ocean Analysis and Forecast product — the Mercator global model.
To trust that current field, he tested it against history first. Using the float’s known track from June 1 to July 12, he simulated 24 hours of drift starting from each day’s position, then checked whether the simulated endpoint lined up with where the float actually was the next day.

For comparison, he ran the same test using surface currents instead — checked against the actual track, the surface-current simulations drift visibly off course.

Looked at on their own, without the historical track for reference, those surface-current simulations don’t reveal anything wrong.

But checked the same way against the real track, the 700-meter-depth simulations hug the historical path far more closely — confirming which current field to trust.

“There’s a lot of randomness, a lot of uncertainty in this. It’s like — a dice roll will take it.”
— Knut-Frode Dagestad
This time, the dice landed within 61 km.
04The Interview
What drew you into oceanography in the first place?
“I wanted to study theoretical quantum physics, or something more hardcore physics. But then I found it interesting, though a little far from everyday life — and very narrow. I think it’s nice to do something more related to everyday life, something normal people can relate to.”
“So then meteorology — that was quite interesting. It was actually more mathematical and physical than I expected, because people on the street would say it’s guesswork. They don’t know how much physics is behind meteorology. I liked that it was relevant to society, and still interesting.”
He grew up about an hour inland from Bergen, Norway — near a lake, not the ocean. But I think most people feel attached to the ocean regardless. For me, though, it wasn’t really the ocean itself — it was more the physics, the problem-solving, and a bit of randomness that led me first into meteorology, and then into oceanography, because the two are so connected — you can’t really study one without the other.”
How did OpenDrift come about?
“We already had a service, with some older models running — but we had three different models in three different programming languages. What we realized is there’s so much overlap between oil-spill modeling, search-and-rescue drift modeling, dust modeling, and iceberg modeling that we just made one framework, with separate models for each specific task built on top of it. So we made one generator instead of three separate ones.”
Knut-Frode has worked at MET Norway for about ten or eleven years, building tools for exactly this kind of problem: modeling where things — oil, people and objects in search-and-rescue cases, dust, icebergs — end up carried by ocean currents.
Did you use machine learning for this prediction?
“We do drift modeling with machine-learning corrections at times, but in this case I didn’t use it, because my colleague who works on the machine-learning side was on vacation, and I didn’t want to disturb him. Next time, we’ll add a machine-learning correction to it.”
“I don’t believe in an approach where you use only machine learning. You need a physical grounding as your basis, and you use machine learning as a correction — a post-processing step for the part you can’t otherwise model, the part you can’t fully understand but can fit with machine learning.”
Any advice for people entering the next contest, or using OpenDrift generally?
“I don’t think I’d give advice, because I think it’s good that there’s variability — that people test different approaches. If everyone agreed on the same advice, we’d all end up more uniform, and it might turn out that an approach we didn’t believe in works better. So I wouldn’t give advice — but for my own sake, I believe in a combination of physics as a foundation and a bit of machine learning. Not too much, but a good combination. It’s a fantastic tool — you just have to figure out where to use it and where not to. I think that’s true not just in oceanography, but in society as a whole.”
On the value of the contest format itself:
“I think this competition is not only fun — it’s really useful for everyone involved. It’s a deadline, and you don’t know the answer, so you really need to think and sharpen yourself before submitting. If you’re a researcher just playing with data you already have, you can be focused, but it’s not the same sharpness.”
05What’s Next
There’s more to come — Knut-Frode will be joining us live for “Finding The Monk: How to Predict Where the Ocean Takes a Float,” a walkthrough of the trajectory-prediction techniques behind this win, including the surface-vs-depth validation test and the forecast run above. Bring your questions — he’ll be there to answer them live.
Save the Date
Finding The Monk: How to Predict Where the Ocean Takes a Float
Tuesday, August 18, 2026 · 9:00 AM PDT

Where's the Monk Contest Challenge Continues : Part 2

01The Challenge Continues!
Our first Where’s the Monk contest wrapped up with a winner — read how José Manuel Echevarría Rubio, PhD Candidate in Marine Sciences at CICIMAR-IPN nailed his prediction — and now we’re back with a new stretch of ocean, a new contest, and a new deadline: July 20, 2026 at 11:59 PM PDT. Position updates revealed until July 13, 2026 at 11:59 PM PDT.
Somewhere along the North Atlantic, a profiling float named “The Monk” is drifting along — guided by currents, thermoclines, and the physics of the ocean. It’s one of Seatrec’s infiniTE™ floats, powered by thermal energy harvested from the temperature gradient between warm surface waters and the cold deep.
We know its last confirmed position. What we don’t know — and what we’re asking you to figure out — is exactly where The Monk will surface on July 20, 2026 at 11:59 PM PDT.
No hints. Just your read of the ocean, or your most inspired guess. Use the live tracker to study its trajectory. Dig into Gulf Stream data. Or go with your gut. Closest guess wins — ties broken by earliest submission.
Contest Brief
|
⏰ Contest Deadline July 20, 2026 · 11:59 PM PDT
|
🔍 Track Live 📅 Position Updates REVEALED Until July 13, 2026 · 11:59 PM PDT |
02What Is the infiniTE™ Float?
The infiniTE™ is Seatrec’s flagship ocean profiling float, designed to operate autonomously for years without battery replacement — harvesting energy from the ocean’s natural temperature gradient to power itself and collect critical oceanographic data on every dive cycle.
The Monk has been tracing the currents of the Atlantic, and its track tells a story of eddies, meanders, and the Gulf Stream system. Where it ends up next is yours to predict.
🏆
Win the Exclusive Seatrec T-Shirt

The winner receives this exclusive Seatrec “Infinite Energy · Deeper Insights” infiniTE™ T-shirt — limited edition, not for sale.
One Winner · Closest Coordinates Wins
03How to Enter
To win the shirt, study the tracker, make your prediction, and submit your coordinates. Closest entry wins. Ties broken by the earliest valid submission. We’ll announce the winner shortly after July 20th.
|
STEP 01 Study the trackerWatch The Monk’s trajectory at the live tracking link. Positions update through July 13, 2026 · 11:59 PM PDT. |
STEP 02 Make your predictionPick a latitude and longitude for where The Monk will surface on July 20, 2026 at 11:59 PM PDT. |
|
STEP 03 Submit coordinatesDrop your numbers into the official entry form before the deadline. |
STEP 04 Win the shirtClosest entry wins. Ties broken by the earliest valid submission. We’ll announce the winner shortly after July 20. |
The Series Continues
The Monk is Continuing its Journey
Our next contest is live. Same float, new currents, new prediction, new chance to win.

We have a Winner! Where's the Monk Contest: Part 1

01We have a Winner!

Our first Where’s the Monk contest asked one question: where would The Monk — one of Seatrec’s infiniTE™ floats, drifting along the North Atlantic — surface on July 5, 2026, at the closest time before 11:59 PM PDT? Predictions came in from around the world. Landing within 100 km of a float that’s been riding the Gulf Stream’s eddies and meanders for two weeks is genuinely hard — only four entries managed it. And when the Monk surfaced at 38.5626°N, 50.6690°W, at 3:27 PM PDT, one prediction stood closest of all, just 52 km away: José Manuel Echevarría Rubio, PhD Candidate in Marine Sciences at CICIMAR-IPN. (Shout out to his advisor, Dr. Guillermo Martínez-Flores!).
02The Results
José Manuel’s prediction (green) landed closest of all, with three more entries (yellow) also within 100 km — a genuinely tough target to hit. The rest of the yellow dots, spread across the map, show just how far the ocean can carry even a well-researched prediction.

The field made it a real race. Entries came in from around the world, and only four landed within 100 km of The Monk’s surfacing position — José Manuel’s the closest among them. Between them, the top four spanned Mexico, France, and both coasts of the United States — and all four are expert oceanographers.

Every entry, ranked by distance. Only four predictions worldwide landed within 100 km.
03The Winning Prediction
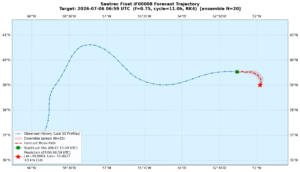 José Manuel’s prediction graphic.
Oceanographers describe moving water in two ways. The Eulerian view watches the ocean from fixed points, like a moored buoy reporting the current flowing past it, or a weather station reporting the wind. The Lagrangian view follows the water itself, like a message in a bottle going wherever the ocean takes it. Predicting The Monk is a classic Lagrangian problem: the float is a kind of diving bottle, and the question is where the ocean carries it.
That is what makes it hard. A Lagrangian forecast has to get many things right at once, and an error in any one of them can grow day by day:
- The mean current — the Gulf Stream is a geostrophic current, driven by sea surface height gradients, that can advect a float over 100 km a day in its core and far less just outside it. Get the current’s strength or position wrong and the whole trajectory shifts.
- Mesoscale eddies — warm-core and cold-core rings, tens to hundreds of kilometers across, that pinch off from meanders in the main current. A float caught in one gets trapped in rotational flow instead of advecting downstream — you can see exactly this looping behavior in The Monk’s track.
- Meanders — baroclinic instability makes the Gulf Stream snake rather than flow straight; whether a given meander sweeps the float north or south of the mean path can matter by hundreds of kilometers.
- Vertical shear — a profiling float spends much of its time below the surface, where current speed and direction can differ substantially from the surface, so the model has to resolve the current field at depth, not just at the surface.
- Chaotic dynamics — Lagrangian trajectories are sensitive to initial conditions; small position uncertainties amplify over time, the same underlying reason weather forecasts lose skill with lead time. A few kilometers of error early on can compound into a much larger miss days later.
- Data latency — position updates stopped on June 28; the prediction target was July 5. That’s seven days of dead reckoning, forecasting motion with no fresh GPS fix to correct against.
For me, it was like a fun programming exercise to also test the methodologies I use as part of my Ph.D.
— José Manuel Echevarría Rubio
A note for any Gen-AI submissions: the four closest entries came from oceanographers; AI-assisted guesses landed about six times farther out. The ocean is a complicated system! Join our webinar on August 18 and learn how the humans did it.
04The Interview
|
▶ CaTCH AN INSIGHT We met with José Manuel to talk about his prediction, his research, and the ocean itself. He’ll be sharing more during a webinar scheduled for August 18th. |
A QUICK SNIPPET BEFORE THE ACTUAL WEBINAR → |
What made you enter Where’s the Monk?
I saw the LinkedIn post, and part of my PhD thesis is modeling the Lagrangian transport of pelagic sargassum.
Walk us through your approach — what data and models did you use?
First, I got the whole track of the float since its deployment in the Gulf of Mexico. I used Copernicus Marine data — the Global Ocean Physics Reanalysis (GLORYS) current fields — with eight depth levels from the surface down to about 900 meters and built a cube of currents. I modeled the float’s trajectory going down into the deepest layer and back up to the surface every 11 hours, at about 0.1 meters per second for the descent and buoyant ascent rate.
I used two different datasets: a reanalysis for the hindcast (past ocean current data) and a forecast product for the actual prediction — which has more uncertainty, so I had to build an envelope of possible trajectories rather than a single path. I ran the simulations using the OpenDrift library, developed by the Norwegian Meteorological Institute. To validate the model, I did a grid search to tune all the parameters against the float’s own past positions (hindcast) before generating the forecast — the same validation approach I use in my PhD work with in-situ drifters for sargassum transport.
What was the hardest part of the prediction? What almost threw you off?
I had to use two different datasets — a reanalysis for the hindcast, the past ocean current data, and a different forecast product for the actual prediction. The forecast has uncertainties; it’s not as accurate, so I had to build an envelope of all the possible trajectories and adjust parameters accordingly. That was the trickiest part.
But it was a good exercise, because it’s the same approach I’m using right now to forecast the date and location of the sargassum beaching events.
The Monk surfaced 52 km from your coordinates. What did you get right?
I followed a good methodology — it wasn’t a lucky guess.
What first drew you to oceanography?
I grew up two blocks away from the Caribbean Sea, and the ocean has always been part of my life. My cousin, who is like my sister, studied marine biology and worked at the National Aquarium in Havana (now a Professor of Marine Science in Spain). I went to the Aquarium frequently with her, and she was the one who introduced me to this field of science.
You’re working on your dissertation — what’s it about, and what’s next for you?
My dissertation is on the factors that are controlling the proliferation of sargassum in the equatorial Atlantic — known as the Great Atlantic Sargassum Belt. First, I need to detect the sargassum, calculate the coverage, and simulate the trajectories. And the final part of my PhD is to try to find what is driving the blooms. Looking ahead, I want to stay right at that intersection, continuing to work on projects that combine remote sensing with ocean modeling to solve complex environmental challenges.
Any advice for people entering the next contest?
The first advice I’ll give is to have a solid ground truth — the past track the float actually took — and validate your model against that in-situ data before you attempt a forecast. Try to do the validation first. I do a lot of machine learning too, and it’s the same principle: you train your model, then validate on data the model hasn’t seen before
Plans after your dissertation defense?
I want to do a postdoc, maybe at the same institution — I’m not sure yet, but for sure I want it to combine remote sensing and physical oceanography. I’ve worked a lot with remote sensing already; for example, I did a project researching kelp forests on the West Coast, in the Pacific Northwest, and I really love kelp forests and the role they play in coastal ecosystems. I want to continue working on combining remote sensing with physical oceanography and ecological modeling. The first advice I’ll give is to have a solid ground truth — the past track the float actually took — and validate your model against that in-situ data before you attempt a forecast. Try to do the validation first. I do a lot of machine learning too, and it’s the same principle: you train your model, then validate on data the model hasn’t seen before
05What’s Next
José Manuel takes home the exclusive Seatrec “Infinite Energy · Deeper Insights” infiniTE™ T-shirt — and he’s not done. He’s going to compete in the next contest, and on Tuesday, August 18, 2026, at 9:00 AM PDT, he’ll join Dr. Paul Chamberlain, Postdoctoral Researcher at Scripps Institution of Oceanography, for our webinar “Finding The Monk: How to Predict Where the Ocean Takes a Float” — a walkthrough of real trajectory-prediction techniques, including how the winning forecast came together. José Manuel will defend his Ph.D. thesis early August, and by the time of our webinar, he will be Dr. Manuel.
The Series Continues
The Monk is Continuing its Journey
Our next contest is live. Same float, new currents, new prediction, new chance to win.
|
Mission Brief The Monk is drifting.On June 23rd, the Monk was at 39.1239°N, 55.4052°W — carried by currents, thermoclines, and the physics of the deep. |
01The Challenge
Somewhere in the North Atlantic, a profiling float named "The Monk" is drifting — guided by currents, thermoclines, and the physics of the ocean. It's one of Seatrec's infiniTE™ floats, powered by thermal energy harvested from the temperature gradient between warm surface waters and the cold deep.
We know its last confirmed position. What we don't know — and what we're asking you to figure out — is exactly where The Monk will surface on July 5, 2026 at 11:59 PM PDT.
No hints. Just your read of the ocean, or your most inspired guess. Use the live tracker to study its trajectory. Dig into Gulf Stream data. Or go with your gut. Closest guess wins — ties broken by earliest submission.
Contest Brief
|
📍 Last Confirmed Position ON 6/23/26 39.1239°N, 55.4052°W ⏰ Contest Deadline July 5, 2026 · 11:59 PM PDT |
🔍 Track Live 📅 Position Updates REVEALED Until June 28, 2026 · 11:59 PM PDT |
02What Is the infiniTE™ Float?
The infiniTE™ is Seatrec's flagship ocean profiling float, designed to operate autonomously for years without battery replacement — harvesting energy from the ocean's natural temperature gradient to power itself and collect critical oceanographic data on every dive cycle.
The Monk has been tracing the currents of the Atlantic, and its track tells a story of eddies, meanders, and the Gulf Stream system. Where it ends up next is yours to predict.
🏆
Win the Exclusive Seatrec T-Shirt
The winner receives this exclusive Seatrec "Infinite Energy · Deeper Insights" infiniTE™ T-shirt — limited edition, not for sale.
One Winner · Closest Coordinates Wins
03How to Enter
|
STEP 01 Study the trackerWatch The Monk's trajectory at the live tracking link. Positions update through June 28, 2026 · 11:59 PM PDT. |
STEP 02 Make your predictionPick a latitude and longitude for where The Monk will surface on July 5, 2026 at 11:59 PM PDT. |
|
STEP 03 Submit coordinatesDrop your numbers into the official entry form before the deadline. |
STEP 04 Win the shirtClosest entry wins. Ties broken by the earliest valid submission. We'll announce the winner shortly after July 5. |
04Coming Soon: Float Modeling Webinars
Seatrec will be hosting webinars on real float-modeling techniques — ocean current analysis, Argo float data, and trajectory prediction with public datasets. Stay tuned for dates.
Drop Your Coordinates
Ready to Outguess the Ocean?
The Monk is waiting to be found. Closest coordinates win.
Submit Prediction →Open Live Tracker
Contest run by Seatrec. No purchase necessary. Open to residents worldwide, ages 13+. Entrants under 18 must have parental permission. Void where prohibited. Winner contacted by email.

Seatrec, Precise Systems, Airtronics to Deliver Persistent Subsea Autonomous Profiler Capability for U.S. Navy
Seatrec, Precise Systems, Airtronics to Deliver Persistent Subsea Autonomous Profiler Capability for U.S. Navy
MOU establishes a manufacturing, integration, and delivery framework combining Seatrec's ocean energy-harvesting technology with Precise Systems' and Airtronics' systems engineering expertise to execute highly scalable and robust PSAP mission capability
VISTA, Calif. and LEXINGTON PARK, Md.— April 16, 2026 — Seatrec, a leader in thermal-powered, long-endurance subsea drones, Precise Systems, a premier defense solutions provider, and its affiliate Airtronics, today announced the signing of a Memorandum of Understanding (MOU) to deliver Persistent Subsea Autonomous Profiler (PSAP) units in support of the U.S. Navy and other customers.
The MOU establishes a framework for partnership and collaboration among the three parties to execute and deliver PSAP units in accordance with approved program deliverables and budget. Central to the agreement is the establishment of a highly scalable manufacturing, integration, and delivery facility in Mississippi. The primary objective is to combine Seatrec's technology with the systems engineering and manufacturing expertise of Precise Systems and Airtronics to execute and deliver a robust, persistent PSAP mission capability.
"This agreement brings together exactly the right capabilities at the right time. Seatrec's energy-harvesting technology fundamentally changes what is possible for persistent undersea operations, and the manufacturing and systems integration depth that Precise Systems and Airtronics bring to this partnership gives us a clear path to delivering PSAP capability at the scale and reliability the Navy requires," stated Yi Chao, Ph.D., CEO and founder of Seatrec.
Seatrec's energy-harvesting core technology, originally developed at NASA's Jet Propulsion Laboratory and commercialized out of the California Institute of Technology in 2016, enables subsea drones to generate electricity from naturally occurring ocean temperature gradients. This approach eliminates the endurance limitations that have historically constrained battery-powered underwater autonomous vehicles, supporting extended missions and enabling the integration of power-intensive sensors, such as hydrophones, that were previously impossible for long-duration deployments.
Precise Systems Chief Executive Officer and President, Scott Pfister, added, "Precise Systems and Airtronics are proud to anchor the manufacturing and systems integration mission for this program. Establishing a dedicated facility in Mississippi reflects our long-term commitment to building scalable, domestic defense production capacity, and our confidence that the PSAP capability we deliver together will meet the Navy's most demanding operational requirements."
The PSAP supports the U.S. Navy's need for persistent, autonomous undersea profiling platforms capable of operating across a range of maritime environments. By pairing Seatrec's renewable energy systems with the proven manufacturing and integration capabilities of Precise Systems and Airtronics, the partnership is positioned to deliver a highly scalable solution that advances undersea warfare readiness and ocean domain awareness.
This partnership is positioned to deliver a scalable solution that advances undersea warfare readiness and ocean domain awareness.
ABOUT SEATREC
Seatrec designs and manufactures subsea drones that generate electricity from ocean temperature gradients. Our products empower defense and oceanographic researchers to extend mission durations, optimize data collection, and reduce operational costs. By enabling the integration of advanced sensors previously limited in endurance and functionality, such as hydrophones, we open new possibilities for ocean science.
Seatrec’s energy-harvesting core technology was developed at NASA’s Jet Propulsion Laboratory and spun out of the California Institute of Technology in 2016. Seatrec is headquartered in Vista, California. Visit us at seatrec.com.
ABOUT PRECISE SYSTEMS
Precise Systems delivers integrated, mission-ready solutions that advance warfighter readiness and strengthen our nation's most critical defense programs. Through combined capabilities spanning Advanced Engineering, Digital Transformation, Electromagnetic Warfare, Interactive Training & Simulation, Physical Sciences Research, Platform Lifecycle Support, and Foreign Military Sales, Precise Systems applies innovative technologies, engineering rigor, and customer-focused execution to solve complex challenges and accelerate mission success. Unified by decades of trusted performance and expanded through strategic growth, Precise Systems is guided by a commitment to partnership, precision, and performance. For more information, visit GoPrecise.com.
ABOUT AIRTRONICS
Established in 1975, Airtronics Inc. is a DOD Government Contractor, currently maintaining hundreds of prime contracts for various agencies of the U.S. Department of Defense, including the Air Force, Army, Coast Guard, Defense Logistics Agency and Navy. Learn more at airtronicsinc.com.
Media Contacts
Marta Bulaich
Seatrec, Inc.
marta.bulaich@seatrec.com
+1 (415) 816-1665
Karen Wathen
Precise Systems
kwathen@goprecise.com
+1 (240) 416-6473

From “How Far from Reality?” to Real-Time Ocean Observation
The North American Gulf Stream as illustrated with the ECCO model.
Credit: Greg Shirah / NASA’s Scientific Visualization Studio
From “How Far from Reality?” to Real-Time Ocean Observation
How Seatrec CEO Yi Chao’s early Gulf Stream research comes full circle in an infiniTE™ Float mission now more than 500 profiles in, from the Gulf of Mexico to the western North Atlantic
Three decades ago, long before Seatrec existed, our CEO and founder, Yi Chao, was working on one of the hardest problems in physical oceanography: how to model the Gulf Stream realistically as it separates from the U.S. coast near Cape Hatteras. Today, a Seatrec infiniTE™ float is tracing that broader Atlantic system in the real ocean, more than 500 profiles into a mission spanning the Gulf of Mexico, the Florida Straits, and the western North Atlantic.

That connection is more than a coincidence. It is the throughline of Yi’s career. During his Ph.D. at Princeton, Yi studied El Niño. After graduate school, he turned to the Gulf Stream because one question kept bothering oceanographers: why couldn’t models reproduce its separation correctly at Cape Hatteras? For years, that gap was more than a technical frustration. It suggested that even advanced ocean models were still missing something essential about North Atlantic circulation.
In 1996, while at NASA’s Jet Propulsion Laboratory, Yi co-authored “Modeling the Gulf Stream System: How Far from Reality?” The paper marked an important advance in showing that the Gulf Stream could be modeled much more realistically than before. It was one of Yi’s earliest papers at JPL and helped establish a question that would shape much of his career.
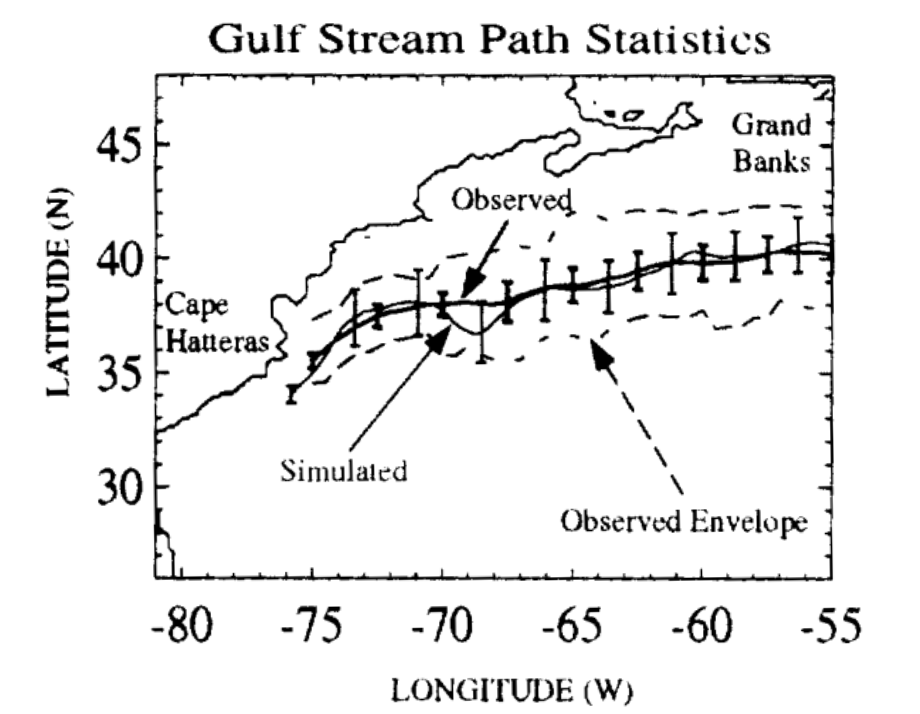
The title of that paper still resonates with us: How far from reality? In many ways, that question sits at the heart of Seatrec. Yi went on to spend roughly 20 years at NASA Jet Propulsion Laboratory working in ocean modeling and satellite oceanography before founding Seatrec in 2016. Our core technology originated at NASA JPL / Caltech, and our mission is to make the ocean more continuously observable by solving one of subsea science’s most stubborn constraints: power.
For decades, oceanographers have had to make difficult tradeoffs. Traditional profiling floats are constrained by primary batteries, which limit mission duration, sampling frequency, and payload flexibility. Satellites transformed our view of the surface ocean, but the subsurface ocean, the heat structure, salinity gradients, mixing, and soundscape, remains much harder to observe persistently. That is the gap Seatrec was built to close.
Seatrec’s answer has been to rethink power from the ocean up. Our infiniTE™ platform harvests electricity from naturally occurring temperature differences between warm surface water and colder depths. As the float cycles through the water column, phase-change materials drive a hydraulic system and generator, producing power for repeated profiling and expanded sensing. The result is a long-endurance platform designed to collect more data, more often, with less dependence on battery replacement and ship support.
This 500-profile mission shows what that looks like in practice. The mission began in the northeastern Gulf of Mexico, south of Destin, Florida. In its first 49 days, the float completed 160 profiles, diving to depths of up to 800 meters while surfacing to transmit real-time data. Equipped with a CTD and passive acoustic hydrophone, it began building a continuous picture of subsurface temperature, salinity, and underwater sound in a region where seeing below the surface matters for both hurricane forecasting and soundscape monitoring.
After 315 profiles, the float entered the Florida Straits, where the mission shifted from broad Gulf drifting to boundary-current sampling. This narrow, deep, high-energy corridor between the Florida Keys and Cuba funnels flow toward the Atlantic and sharpens vertical and horizontal gradients. In this phase, the float was completing about four profiles per day, creating a much denser record of changing subsurface conditions through one of the most dynamic passages in the western Atlantic.
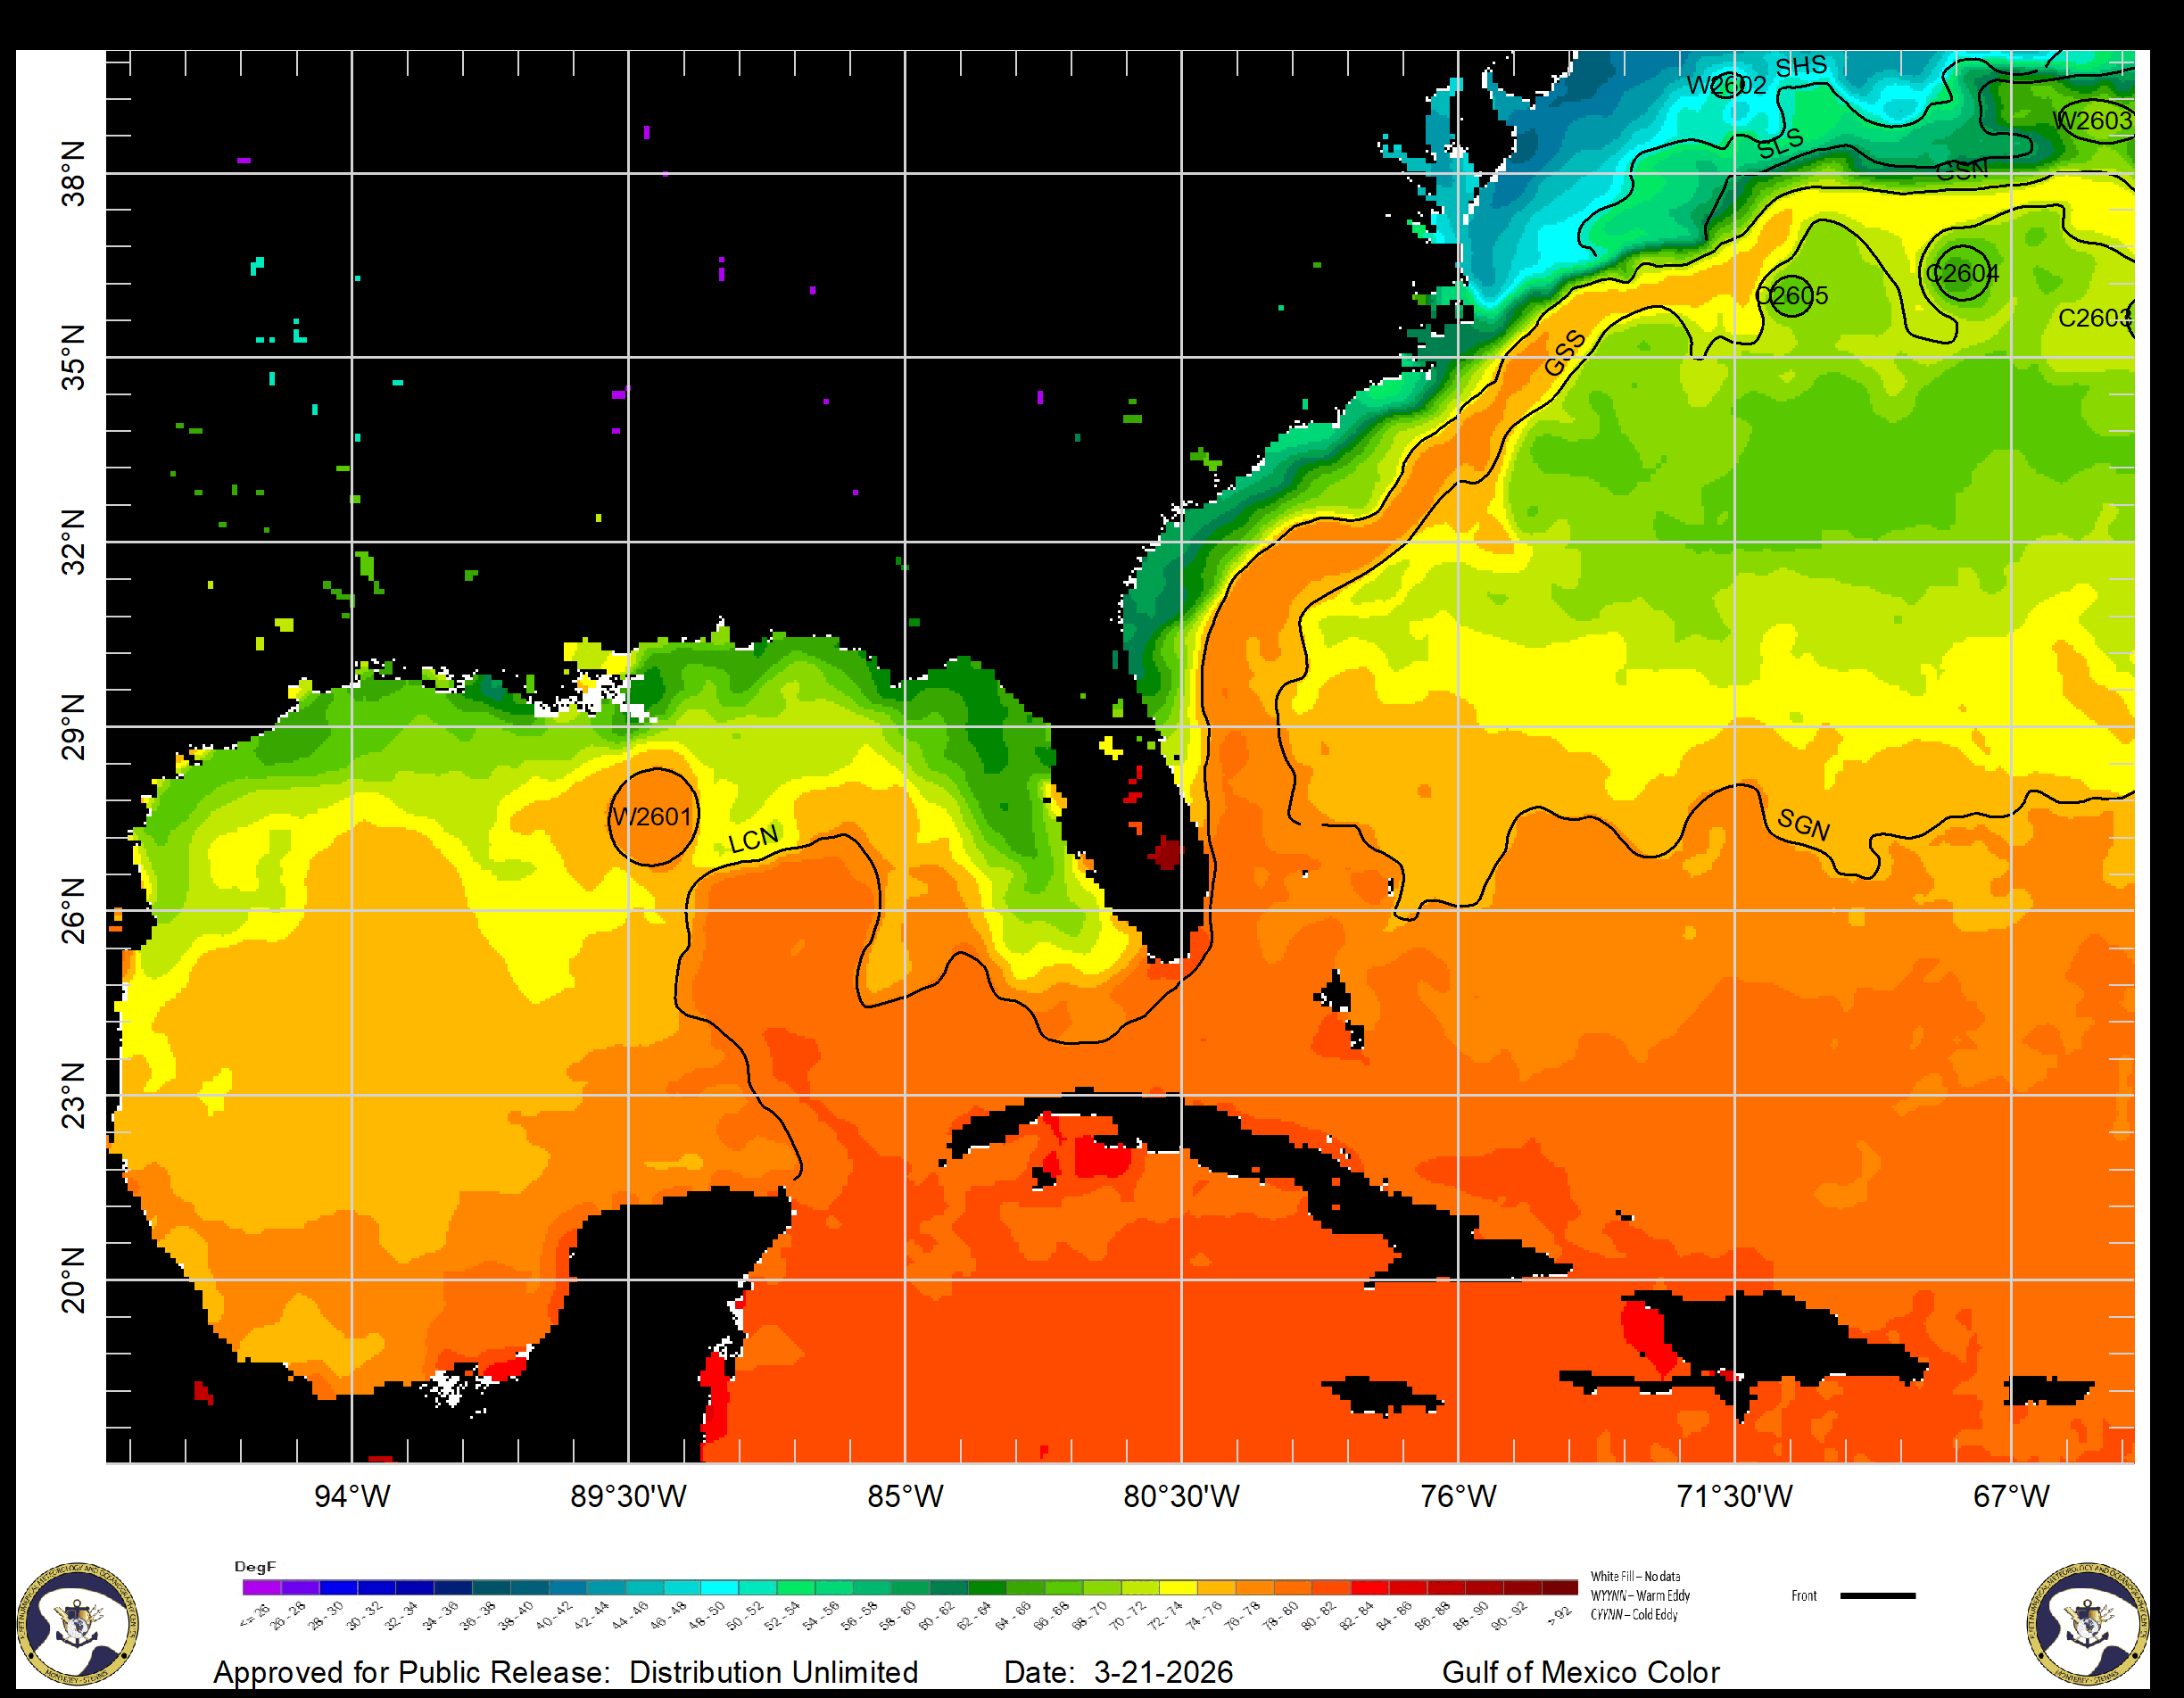
By 480 profiles, the mission had advanced from the Gulf of Mexico through the Florida Straits, up the U.S. East Coast, setting up the next chapter as the float entered the Gulf Stream separation region off Cape Hatteras, the same broader system that defined an early chapter of Yi’s scientific career. What once lived in model grids is now being sampled profile by profile by an autonomous float powered by the ocean’s own thermal gradients.
That is why this milestone feels bigger than a number. Yes, 500 profiles is an operational achievement. But it is also a reminder that the best ocean technology does more than last longer. It changes what is scientifically possible. Seatrec’s milestone is not that this is the first float to sample the Gulf Stream. It is that a thermally powered float is delivering persistent, high-frequency profiling across multiple connected ocean regimes, without the same battery limits that have historically constrained mission duration and sensor use.
Persistent subsurface measurements help reveal the hidden heat structure that can fuel hurricane rapid intensification. They support better understanding of ocean heat transport and water-column structure across connected current systems. And when acoustic sensing is added to the same long-endurance platform, they can also contribute to persistent soundscape monitoring.
For Seatrec, this is a field report. For Yi, it is a full-circle moment. Three decades after asking how far ocean models were from reality, he now leads a company building tools that can stay in that reality longer, profiling through it, transmitting from it, and helping make the ocean more continuously observable. Few scientific careers draw such a direct line from question to platform. This one does.
And the float is still going.
Live tracking: seatrec-floats.com
Data access and collaboration: info@seatrec.com
Seatrec’s infiniTE™ Profiling Float Captures First-of-Its-Kind Fine-Scale Ocean Vertical Structure
Seatrec’s infiniTE™ Profiling Float Captures First-of-Its-Kind Fine-Scale Ocean Vertical Structure, Powered by Temperature Gradients
A serendipitous meeting between ocean engineers and scientists sparked a new float mission to change how the ocean is measured
VISTA, Calif.— Feb. 23, 2026 — Seatrec, a leader in thermal-powered, long-endurance subsea drones, today announced the successful launch of a collaborative scientific mission to develop new autonomous profiling float capabilities that are powered by the ocean’s temperature differences and collect critical data on ocean health and carbon cycling.
This mission originated from a booth conversation at the American Geophysical Union (AGU)-sponsored Ocean Sciences Meeting 2024 (OSM24), held in New Orleans in February 2024. Seatrec CEO and Founder, Yi Chao, Ph.D., met with Mark Altabet, Ph.D, Professor and Chair of the School for Marine Science & Technology at the University of Massachusetts Dartmouth, and Eric A. D’Asaro, Ph.D., Senior Principal Oceanographer of the Applied Physics Laboratory and School of Oceanography at the University of Washington. At the time, Seatrec had recently launched its commercial infiniTE™ float. During discussions, Altabet and D’Asaro explored how the infiniTE float could fundamentally alter sampling strategies for studying turbulence, internal waves, and ocean mixing. That discussion marked the beginning of a co-development effort.
“Data below the ocean surface is significantly lacking because traditional profiling floats are all powered by primary batteries that limit float life and data collection capability,” explained Chao. “The infiniTE float harvests energy from temperature gradients in the ocean, and can therefore collect more frequent measurements and carry new sensors.”
The collaboration resulted in the successful development and deployment of an infiniTE float with two sensors to measure oxygen and total dissolved gas pressure (TDGP), key indicators of ecosystem health, environmental stress, and carbon cycling. The accurate measurement of TDGP requires the float to park at multiple depths and remain at each depth long enough for the sensor to collect reliable measurements.
“This type of mission has never been done before with the existing float products,” said D’Asaro. “The infiniTE float changes the way we think about power in a profiling float. In a battery-powered float, the total energy is fixed, so you try to minimize power usage by minimizing the number of profiles. Since the infiniTE float recharges its battery with the energy harvested from the ocean, there is no power penalty for more profiles.”
“Looking into the future,” said Altabet, “the infiniTE float can be used to profile more rapidly to resolve the diurnal variation of oxygen and its impact on productivity. This could only be done with the infiniTE float in a sustained way.”
This mission builds on Seatrec’s broader efforts to advance long-duration autonomous ocean systems, including a Cooperative Research and Development Agreement (CRADA) with the Naval Postgraduate School focused on enabling persistent, real-time oceanographic and acoustic measurements in open-ocean environments.
Related to this work, Chao will present at this week’s AGU Ocean Sciences Meeting in Glasgow, Scotland, on harvesting energy from ocean temperature gradients to power underwater robots and sensors for persistent monitoring.
About Seatrec
Seatrec designs and manufactures subsea drones that generate electricity from ocean temperature gradients. Our products empower defense and oceanographic researchers to extend mission durations, optimize data collection, and reduce operational costs. By enabling the integration of advanced sensors previously limited in endurance and functionality, such as hydrophones, we open new possibilities for ocean science.
Seatrec’s energy-harvesting core technology was developed at NASA’s Jet Propulsion Laboratory and spun out of the California Institute of Technology in 2016. Seatrec is headquartered in Vista, California. Visit us at seatrec.com.
About the School for Marine Science & Technology, University of Massachusetts Dartmouth
The School for Marine Science & Technology at the University of Massachusetts Dartmouth (SMAST) is a nationally and internationally recognized institution for education and research in marine science and ocean technology. SMAST is a collaborative community of dedicated students and expert faculty working together to address critical challenges in marine science while fostering a supportive and collegial environment. SMAST students and faculty help address urgent issues facing the world’s oceans, including climate change and ocean impacts, food security via sustainable fisheries, sustainable energy development and associated impacts, and coastal ecosystem resilience.
About the Applied Physics Laboratory, University of Washington
The University of Washington Applied Physics Laboratory (APL-UW) was founded by the U.S. Navy in 1943 to conduct acoustic and oceanographic studies on how deep ocean variability affects Navy systems. Today, APL-UW scientists and engineers lead research and applied technologies in acoustic and remote sensing, ocean physics and engineering, medical and industrial ultrasound, polar science and logistics, environmental and information systems, and electronic and photonic systems.
Media Contact
Marta Bulaich
Seatrec, Inc.
marta.bulaich@seatrec.com
+1 (415) 816-1665

Seatrec infiniTE™ Gulf Mission Update: 315 Profiles — Now in the Florida Straits
Seatrec infiniTE™ Gulf Mission Update: 315 Profiles — Now in the Florida Straits
Since our last update on November 4, the infiniTE™ float has completed 155 additional profiles and is now entering the Florida Straits, a narrow, high-energy corridor between the Florida Keys and Cuba where Gulf waters accelerate toward the Atlantic. The straits present markedly different sampling conditions: sharp frontal boundaries between water masses and rapidly varying subsurface structure to 800 m depth.
Current mission totals
-
Profiles completed: 315
-
Profiling depth: 800 meters
-
Total Energy harvested: 2.609 MJ
-
Sampling interval: ~every 6 hours
-
Data transmission: near real-time via satellite after each surfacing

The Florida Straits sampling context
The Florida Straits form a narrow, deep passage connecting the Gulf of Mexico to the Atlantic Ocean between the Florida Keys and Cuba, concentrating both flow and vertical structure over a short horizontal scale.
Geometry: At the narrowest point, the straits are ~93 miles (150 km) wide yet exceed 1,800 m in depth, creating a confined deep channel between shallow coastal shelves. This geometry funnels flow and steepens horizontal and vertical gradients in temperature and velocity.
The Florida Current: The Florida Current accelerates as it exits the Gulf, with mean surface velocities of 4–6 mph (6.5–9.5 km/h). These speeds increase horizontal advection between profiles and sharpen frontal boundaries encountered during repeated sampling.
Long-term monitoring: Current transport through the straits has been monitored nearly continuously since 1982 by NOAA's Atlantic Oceanographic and Meteorological Laboratory, producing over 14,000 daily transport estimates. This long record provides a well-characterized dynamical context for new subsurface observations.
From Gulf drifting to boundary-current sampling
For its first 315 profiles, the float drifted across the Gulf of Mexico, building a broad picture of subsurface temperature and salinity conditions.
In the Florida Straits, the situation changes. Strong currents carry the float tens of kilometers between profiles, and water properties can change quickly over short distances. This means each profile reflects not only changes over time, but also differences from one location to the next.
Compared with the interior Gulf, these faster currents and sharper boundaries make the Florida Straits a more challenging environment to sample and interpret, requiring frequent, repeated measurements.
What’s being measured every cycle
Every ~6 hours the float dives, profiles, surfaces, and transmits data.
CTD (Conductivity–Temperature–Depth): Profiles salinity and temperature through the upper ocean to reveal layering, mixing, and subsurface heat structure—information satellites cannot observe.
Hydrophone: Records the underwater soundscape. Onboard processing compresses acoustic data for near-real-time transmission via satellite.
How it’s powered (no battery replacement required)
infiniTE™ is powered by Seatrec’s thermal energy harvesting system using phase-change materials (PCMs). As the float cycles between warm surface water and cold deep water, the PCM expands and contracts during phase transition, driving a hydraulic system and generator to produce electricity.
This enables sustained operation at approximately four profiles per day over multi-month deployments without battery replacement.
Collaboration opportunities
Seatrec is seeking collaborators focused on:
- Subsurface heat transport and model validation
- Gulf/Florida Straits soundscape ecology
- Long-duration autonomous sensing
Interested in data access or deploying similar technology? Contact info@seatrec.com.